Perception and Collaboration in Robotics - Session 18
Explore cutting-edge research on perception and collaboration in robotics and AI, focusing on advancements in sensing, decision-making, and multi-agent systems.
Haptics - Session 7
Explore haptic technology and its applications in virtual reality, robotics, and human-computer interaction. Discover latest advancements and potential future developments in tactile feedback systems.
Tracking Techniques in Computer Vision - Session 25
Explore advanced tracking techniques and algorithms for object detection and motion analysis in computer vision applications.
Fruit-Picking Robots Powered by Kubernetes - From Science Fiction to Reality
Explore how autonomous drones use AI and Kubernetes to revolutionize fruit harvesting, addressing labor shortages and overcoming edge deployment challenges in remote agricultural settings.
Love, Death and Robots - Running Wasm and Kubernetes on Boston Dynamics Spot
Explore containerization and Kubernetes on Boston Dynamics Spot robot, including Wasm integration, migration steps, and lessons learned for reliable, secure, and autonomous industrial robotics.
Transitioning to a Custom Kubernetes Operator for API Gateway Management
Explore Ubisoft's journey to a self-service API Gateway using a custom Kubernetes Operator. Learn about challenges, solutions, and benefits of this transition for scalable platform management.
Cloud Native Edge Computing with KubeEdge - Updates and Future
Explore KubeEdge's latest updates, new user adoptions, and future developments in cloud-native edge computing. Learn about recent features and applications in satellites, vehicles, and offshore oil fields.
Preparing Linux Real-Time Kernel and Tuning Robotics Platform with Modern ARM64 SoC
Explore real-time Linux kernel preparation and tuning for robotics on ARM64 SoC, covering configuration, testing, debugging, system optimization, and performance evaluation techniques.

Realtime Linux - Birds of a Feather Session
Explore real-time Linux capabilities and advancements with Google expert Steven Rostedt in this insightful Birds of a Feather session.
Self Driving Car Simulation 3 - Collision Avoidance
Learn to implement collision avoidance in self-driving car simulations using Unity, enhancing vehicle perception and safety features.
Wicked Problem: AI and the Future of Everything - Challenges and Opportunities
Explore the complex challenges and potential of AI's rapid growth, including regulation, societal risks, and its impact on various sectors, with insights from leading experts.
On the Road to Artificial Intelligence
Explore breakthrough AI technologies and their potential impact on society, from autonomous vehicles to assistive robotics, with insights from a leading expert in the field.
Truly Optimal Euclidean Spanners
Explore optimal Euclidean spanners, their construction, and applications in computational geometry and network design. Gain insights from experts Hung Le and Shay Solomon.
Theoretical Foundations of Reinforcement Learning
Explore key concepts and mathematical principles underlying reinforcement learning algorithms, including Markov decision processes, value functions, and policy optimization techniques.
Integrating Telepresence with Docker Desktop - Enhancing Cloud-Native Development
Explore the integration of Telepresence and Docker Desktop, enabling faster local-to-remote feedback loops and improved testing for cloud-native engineers. Learn about implementation challenges, benefits, and new workflows.

Determining When Robots Will Rule the World
Explore the future of AI with Ben Goertzel and humanoid robots as they discuss the timeline for artificial intelligence surpassing human capabilities and its potential impact on society.
Will a Robot Steal My Job? - The Future of Work and Automation
Experts discuss the impact of automation and AI on future employment, exploring potential scenarios of job displacement and societal changes due to technological advancements.
A New Social Robot Unveiled Live on Stage
Unveiling of groundbreaking social robot by Furhat Robotics, showcasing advanced conversational AI and potential industry impact through an innovative stage demonstration.
Introduction to KubeEdge - Kubernetes Native Edge Computing Framework
KubeEdge扩展Kubernetes到边缘计算,提供云边协同能力。介绍其动机、架构、新特性、用户采用情况、SIG更新和子项目,并探讨未来发展方向和贡献者参与方式。
Designing Dope Distributed Systems for Outer Space with High-Fidelity Simulation
Explore high-fidelity simulation techniques for developing distributed space systems, with insights from the VISORS solar science mission. Applicable to various domains including robotics and service-oriented architectures.
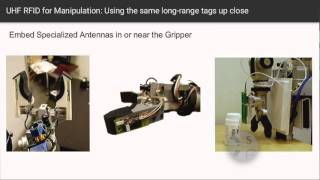
RFID-Enhanced Robots Enable New Applications
RFID-enhanced robots enable innovative applications in healthcare, asset tracking, and remote sensing, offering new possibilities for inventory management, object retrieval, and environmental monitoring.