Beaglebone Black Lessons
Learn to program and control Beaglebone Black, from GPIO pins and PWM to advanced projects like GPS tracking. Gain hands-on experience with Python, hardware interfacing, and data visualization.
Micro-Bit Quad Robot With MakeCode
Learn to control a SMARS Quad robot using MakeCode and BBC micro:bit. Covers hardware setup, leg configuration, movement commands, and programming, with a live demo and downloadable resources.
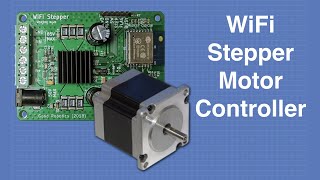
WiFi Stepper Motor Controller with Web-Based Interface
Learn to control a stepper motor via WiFi using a versatile controller. Explore various modes, web interface, and scripting for precise motor control in robotics and automation projects.
Elegoo Smart Robot Car - Collision Avoidance and Line Following
Learn to implement collision avoidance and line following capabilities for Arduino-based robot cars using ultrasonic sensors, servo motors, and optical arrays. Includes code explanations and demonstrations.

Raspberry Pi Pico
Introduction to the Raspberry Pi Pico microcontroller, covering MicroPython installation, LED control, and comparisons with Raspberry Pi Zero. Explores specifications and potential applications.
Controlling a Servo with Arduino
Control a servo motor with Arduino through step-by-step examples, covering basics, schematics, libraries, programming, and advanced techniques like sweeping.

Raspberry Pi Pico - Inputs & Servo Control
Learn to control inputs and servos with Raspberry Pi Pico using MicroPython. Hands-on tutorial covers switches, potentiometers, LEDs, and SG90 servo, with code and wiring diagrams provided.
Using ChatGPT to Write Raspberry Pi Python Code
Explore using ChatGPT to generate and edit Python code for controlling LEDs, servos, and cameras on Raspberry Pi, demonstrating AI's potential in programming and hardware interaction.
Controlling a Servo with Raspberry Pi and Python
Learn to control a servo motor using Raspberry Pi and Python, including accurate positioning, PWM commands, and programming techniques for precise servo movement.
MicroPython Workshop
Hands-on workshop for programming ESP8266 boards with MicroPython. Learn to control LEDs, servos, sensors, and communicate via HTTP/MQTT. No prior electronics experience needed.
Building a Robot Arm with .NET 5, Raspberry Pi, Blazor and Signal R
Learn to build and control a Raspberry Pi-powered robot arm using .NET 5, Blazor, and SignalR. Explore GPIO control, servo movement, and remote operation through a web interface.