
A Strange But Elegant Approach to a Surprisingly Hard Problem - GJK Algorithm
Explore the ingenious Gilbert Johnson Keerthi algorithm for detecting object collisions, covering convexity, Minkowski sums, support functions, and implementation details in 2D space.

Big Stepper Motors with Arduino
Learn to control large NEMA 23 stepper motors using Arduino and microstep driver modules. Covers motor specifications, driver selection, wiring, and programming with basic sketches and the AccelStepper library.
Control Large Gearmotors with PWM and Arduino
Learn to control large DC gearmotors using PWM and Arduino with the Cytron MD10C H-Bridge controller. Explore efficient motor control techniques and high-frequency PWM for improved performance.

Building the Elegoo Smart Robot Car - Arduino Based Robotics Project
Step-by-step guide to assembling an Arduino-based Elegoo Smart Robot Car, covering component overview, assembly process, and initial testing of this versatile educational robotics project.

Using Servo Motors with Arduino
Master servo motor control with Arduino, from basic operations to advanced multi-servo projects using PCA9685. Gain practical skills for robotics and automation applications.

Wireless Joystick for Arduino Robot Car with NRF24L01+
Learn to build a wireless joystick for Arduino robot cars using nRF24L01+ modules. Covers module setup, RadioHead library usage, and practical demonstrations for remote sensing and control projects.

Stepper Motors with Arduino - Controlling Bipolar and Unipolar Stepper Motors
Comprehensive guide to controlling bipolar and unipolar stepper motors with Arduino, covering theory, specifications, and practical implementations using various driver boards.
Controlling a Servo with Raspberry Pi and Python
Learn to control a servo motor using Raspberry Pi and Python, including accurate positioning, PWM commands, and programming techniques for precise servo movement.

Understanding How to Use a Stepper Motor
Learn to control stepper motors with Arduino, including direction and speed adjustments. Hands-on tutorial covers wiring, programming, and troubleshooting for precise motor control in various applications.
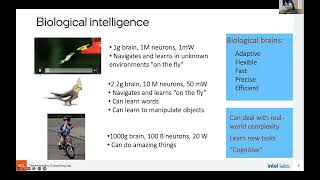
Neuromorphic Intelligence and Learning in Robotics
Explore neuromorphic engineering for efficient AI in robotics, focusing on on-chip learning and processing algorithms using Intel's Loihi 2 chip and the Lava software framework.
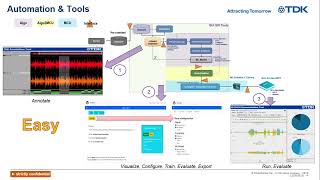
Sensors and Machine Learning: Waking Smarter for Less
Explore how machine learning optimizes sensor systems, reducing resource usage while improving response. Learn about smart wake-up strategies and efficient data conversion at the edge.
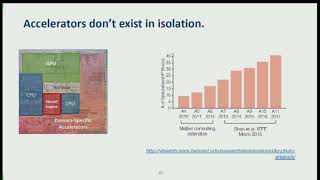
Next-Generation Deep-Learning Accelerators: From Hardware to System - tinyML Summit 2022
Explore next-gen deep learning accelerators, focusing on system-level challenges and opportunities in design, integration, and scheduling for future AI hardware advancements.
Driving with Attention
Explore innovative sensor fusion techniques for autonomous driving, focusing on TransFuser and NEAT models that leverage attention mechanisms to improve perception and decision-making in complex traffic scenarios.
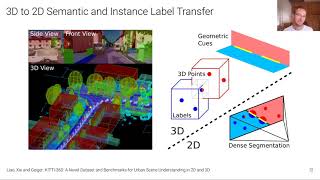
KITTI-360 - A Novel Dataset and Benchmarks for Urban Scene Understanding in 2D and 3D
Comprehensive dataset and benchmarks for urban scene understanding, combining computer vision, graphics, and robotics to advance autonomous driving technology.
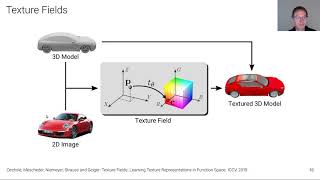
Learning 3D Reconstruction in Function Space
Explore neural implicit 3D representations for geometry and texture reconstruction, discussing their advantages, limitations, and applications in computer vision and graphics.
Raspberry Pi Pico for Robotics
Explore the powerful, affordable Raspberry Pi Pico microcontroller for robotics projects. Learn its features, capabilities, and how to program it using MicroPython, comparing it to other popular boards.
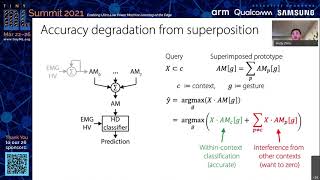
Memory-Efficient, Limb Position-Aware Hand Gesture Recognition Using Hyperdimensional Computing
Memory-efficient hand gesture recognition using hyperdimensional computing and sensor fusion. Improves accuracy by 17.79% while reducing memory footprint, addressing limb position changes for human-machine interfaces and prosthetics.
SCARA Robot - How to Build Your Own Arduino Based Robot
Comprehensive guide to building an Arduino-based SCARA robot, covering design, 3D printing, assembly, electronics, kinematics, and programming with a custom GUI for control.

Arduino Ant Hexapod Robot
Learn to build an Arduino-powered hexapod robot resembling an ant, complete with functional eyes, antennas, and mandibles. Covers 3D modeling, assembly, circuit design, PCB creation, and Arduino programming.
How to Build an Automated Arduino-Controlled Ouija Board
Learn to create an Arduino-controlled Ouija board with self-moving pieces using CNC technology. This tutorial covers hardware setup, wiring, and Arduino programming for an impressive escape room prop or interactive game.
Arduino Fruit Machine Feature Reel - Reverse Engineering and Arduino Control
Explore the inner workings of a fruit machine's feature reel, learn to connect its components to an Arduino, and discover the process of reverse engineering without a manual.