Accelerate Local Development on Kubernetes Using Telepresence
Accelerate local Kubernetes development with Telepresence, a CNCF proxying tool. Maintain a fast feedback loop while building microservices, enabling quick code changes and immediate impact visualization.
Symbolic Computations and Dynamic Visualization in Robotics Research and Education
Explore symbolic computations and dynamic visualizations for robotics research and education using Wolfram Mathematica, enhancing understanding of complex robotic systems.
RT-2: Vision-Language-Action Models Transfer Web Knowledge to Robotic Control
Explore vision-language-action models for robotic control, enhancing generalization and semantic reasoning through Internet-scale data integration and end-to-end training.
A General-Purpose Robotic Navigation Model
Explore advancements in general-purpose robotic navigation models, including data sharing across robots, generalization capabilities, and applications like kilometer-scale navigation and open-vocabulary instruction following.
Hierarchical Perspective on Robotic Control
Explore hierarchical control strategies for complex robotic systems, focusing on dynamically stable behaviors in 3D hopping and planar bipedal robots. Learn about geometric and nonlinear control in hierarchical architectures.
From Words to Actions - Foundation Models for Generalist Robot Brains
Explore the potential of Foundation models in robotics, discussing lessons from scaling robot data collection and strategies to leverage these models for practical applications.
Foundation Reward Models for General Robot Skill Acquisition
Explore foundation reward models for general robot skill acquisition, leveraging non-robot data to enhance adaptability in unstructured environments.
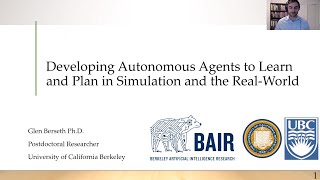
Developing Robots that Autonomously Learn and Plan in the Real World
Explore autonomous robot learning and planning, covering challenges, techniques, and future directions in creating versatile AI agents capable of solving complex real-world tasks.
Generalizable Robotic Agents Through Large-Scale Simulation
Explore how large-scale simulation training produces proficient robotic agents capable of real-world navigation and manipulation using only RGB sensors, guided by language instructions.
View Transformers for 3D Manipulation in Robotics
Explore state-of-the-art View Transformers for 3D object manipulation in robotics, including RVT and RVT-2, offering improved task success, faster training, and real-world applicability.
Mila Robot Learning Seminar
Explore cutting-edge robot learning techniques and advancements in AI-driven robotics through expert presentations and discussions at the Mila seminar.
See to Act, Act to See - The Interdependence of Planning and Perception in Robotics
Explore the interdependence of planning and perception in robotics, focusing on physical property learning, multi-modal sensing, and uncertainty modeling for improved task performance.
Engineering AI Systems and AI for Engineering: Compositionality and Physics in Learning
Explore compositional AI system design and physics-integrated learning algorithms for robotics and autonomy. Discover methodologies for reliable deployment and rapid hardware control implementation.
Becoming Bionic: Advancements in Smart Prosthetic Limbs
Explore cutting-edge research in prosthetics and smart limb control. Discover open problems and current solutions in neuroprosthetics, reinforcement learning, and human-robot interaction for improved functionality and usability.
Foundational Models for Robot Control
Explore recent advancements in using large pretrained networks for robot control, from basic concepts to practical applications in robotics research.
Efficient Action Representation for Robot Learning
Explore efficient action representation techniques for enhancing robot learning, focusing on helpful abstractions and theoretical aspects of reinforcement learning.
Building General-Purpose Home Robots
Explore advancements in general-purpose home robots, including vision-language models, rapid skill learning, and multi-fingered dexterity. Discover challenges and solutions for creating adaptable, cost-effective domestic assistants.
Robotic Dexterous Manipulation - Advances in Learning and Teleoperation
Explore advancements in robotic manipulation, combining classical and learned methods. Discover projects on extrinsic contact learning, visuo-tactile SLAM, and in-hand object rotation using vision and touch.
Building Adaptable Generalist Robots
Explore cutting-edge approaches for building adaptable generalist robots, focusing on in-context learning, unsupervised reinforcement learning, and leveraging foundation models for improved generalization and task versatility.
Towards Large Behavior Models: Versatile and Dexterous Robots via Supervised Learning
Explore advancements in machine learning for robotics, focusing on creating versatile and dexterous robots through supervised learning and the development of Large Behavior Models.
Learning Abstractions from Humans for Generalizable Robot Learning
Explore methods for integrating human knowledge into robot learning abstractions, focusing on feedback as a prior, personalized interface, and framework for user-aligned reward functions.