Structure in Motion - Geometric Insights in Protein Folding, Robot Kinematics, and Auxetic Materials
Explore geometric insights on protein folding, robot kinematics, and auxetic materials. Discover analogies and structural characteristics in this presentation by mathematics and computer science professors Borcea and Streinu.
Vision, Touch & Sound for Robustness & Generalizability in Robotic Manipulation
Exploración de representaciones de datos perceptuales para mejorar el aprendizaje y desempeño de robots en manipulación, combinando visión, tacto y sonido para mayor robustez y generalización.
Jeremy Bailenson: Your Mind on the Metaverse
Explore the psychological impact of virtual reality and its transformative potential in education, training, and communication, with insights on innovative applications and future implications.
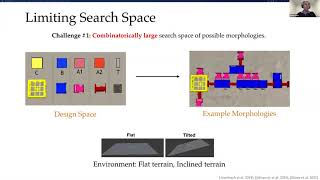
Towards Understanding and Building Embodied Intelligence
Exploring embodied intelligence: evolution, morphology, and learning in complex environments. Insights into AI agents' adaptability and performance using the DERL framework.
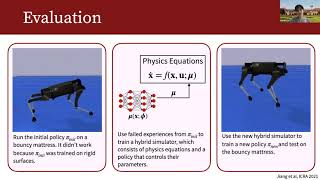
The New Role of Physics Simulation in AI
Explore advancements in physics simulation for AI, focusing on overcoming sim-to-real gaps and improving human-robot interactions through learnable physics engines and efficient training techniques.
AI and Robotics: Current Challenges and Future Directions
Explore AI and robotics with Chelsea Finn and Andrew Ng, discussing career paths, current capabilities, challenges, and future prospects in the field. Gain insights into robotics research and learn how to enter this exciting domain.
Forecasting Disruption: Assessing Technological Risks and Opportunities
Explore forecasting techniques to assess technological disruptions' impact on business models, with insights on evaluating risks and opportunities to inform strategic decisions.
Building Safe and Reliable Autonomous Systems
Explore techniques for developing safe, trustworthy AI systems in critical sectors, focusing on reliability and robustness using advanced machine learning methods.
Stanford Seminar - On and Out-of-Body Interactions & Experiences
Explore novel interaction techniques for on-body and out-of-body technologies, including wearables, robots, and drones, to enhance human-machine integration and extend physical abilities.
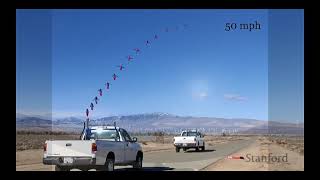
Robots in Dynamic Tasks - Learning, Risk, and Safety
Explore advanced robotics in dynamic environments, covering autonomous drones, aerial manipulators, and risk-aware planning. Learn about machine learning applications, nonlinear control, and adaptive strategies for complex robotic tasks.

Stanford Seminar - Towards Shape Changing Displays and Shape Changing Robots
Exploring shape-changing systems in haptic interfaces and robotics, focusing on physical interaction, adaptive displays, and innovative truss robots for enhanced functionality and manipulation.
Stanford Seminar - From Open-Source to Safety-Certified Robotic Software
Exploring the evolution of ROS from open-source to safety-certified software for robotics and automotive applications, discussing challenges, improvements, and future prospects in the field.

Safety and Liveness of Robot Behaviors
Explore formal methods for designing robots, guaranteeing behavior, and identifying potential issues. Learn about safety and liveness properties in robotic systems, including multi-robot and human-robot interactions.
Distributional Representations and Scalable Simulations for Real-to-Sim-to-Real
Explore challenges and solutions in representing deformable objects, using distributional approaches and differentiable simulators for real-to-sim applications in robotics and autonomous systems.
Stanford Seminar - Deploying Autonomous Service Mobile Robots, and Keeping Them Autonomous
Explore challenges and solutions in deploying autonomous mobile robots in dynamic environments, covering robustness, failure anticipation, and efficient adaptation to user needs through advanced perception and learning techniques.
Stanford Seminar - Robot Manipulation in the Logistics Industry
Exploring challenges and advancements in robot manipulation for logistics, including intelligent systems handling diverse objects, integrating with existing workflows, and operating safely alongside humans.
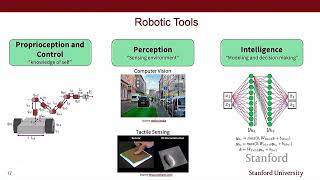
Considerations for Human-Robot Collaboration
Explore the future of human-robot collaboration, focusing on effective teamwork, contextual understanding, and the unique challenges of integrating robots into human-configured environments.
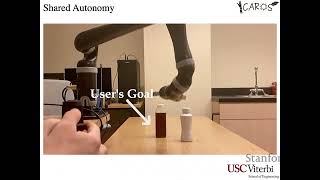
Towards Robust Human-Robot Interaction - A Quality Diversity Approach
Exploring diverse human-robot interaction scenarios using quality diversity algorithms to discover failure cases, improve scenario generation, and enhance understanding of complex systems.
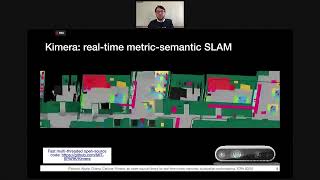
Opening the Doors of Robot Perception - Luca Carlone
Explore cutting-edge spatial perception algorithms for robots, including 3D scene understanding, metric-semantic mapping, and certifiable perception techniques for robust and reliable autonomous systems.
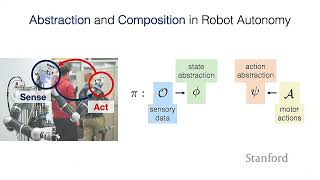
Stanford Seminar - Objects, Skills, and the Quest for Compositional Robot Autonomy
Explore compositional robot autonomy through state-action abstractions, object representations, and sensorimotor skills. Discover innovative approaches for building scalable and generalizable autonomous systems.
Investing in Robotics, Cybersecurity, and Enterprise IT
Explore robotics, cybersecurity, and enterprise IT investment trends with insights from a venture capital expert, covering emerging technologies and industry challenges.