
Easy SLAM with ROS Using Slam Toolbox
Learn to implement SLAM for mobile robots using ROS and slam_toolbox. Covers setup, mapping, localization, and practical application on real robots. Ideal for beginners in robotics and autonomous navigation.
Control Your ROS Robot From Your Phone
Learn advanced ROS robot control techniques, including web servers, Foxglove Studio, RViz Teleop, and stamped twists. Explore simulation improvements and alternative teleop tools for enhanced mobile robotics.

Easy Wireless Control for Your Homemade Robot
Learn to control homemade robots wirelessly using game controllers. Explore Linux and ROS integration, joystick-to-command conversion, and real-time feedback visualization in RViz.
Solving the Problem Every Robot Has - With ROS2_Control
Overview of ros2_control implementation in Gazebo simulation, covering hardware interfaces, controllers, and practical setup for robotic systems.
How to Get Your Robot to See in 3D - Depth Cameras in ROS
Learn to integrate depth cameras with ROS for 3D vision in robotics. Covers simulation in Gazebo, real camera setup (OAK-D Lite), and point cloud visualization for enhanced robot perception.

How to Use Cameras in ROS - Sim Camera and Pi Camera
Comprehensive guide on integrating cameras in ROS, covering theory, simulation, image viewing, compression, and real camera connections for robotics applications.

How Do We Add LIDAR to a ROS Robot?
Learn to integrate LIDAR into ROS robots, covering URDF modifications, Gazebo simulation, and real hardware integration. Gain practical insights for enhancing robot perception capabilities.

The Ultimate Guide to Using Motors in Robotics - Including ROS, Raspberry Pi
Comprehensive guide on integrating motors in robotics, covering hardware connections, control methods, and ROS implementation using Raspberry Pi. Includes practical demonstrations and code examples.
Driving Your Virtual Robot
Learn to simulate and control a virtual robot in Gazebo, covering spawning, launch files, control plugins, teleop, friction adjustment, RViz visualization, and obstacle course creation.
Simulating Robots with Gazebo and ROS - Getting Ready to Build Robots with ROS
Learn to simulate robots using Gazebo and ROS, covering installation, robot spawning, joint control, virtual world creation, and sensor integration. Gain practical skills for advanced robotics development.
How Do We Describe a Robot? With URDF! - Getting Ready to Build Robots with ROS
Learn to describe robots using URDF (Unified Robot Description Format) in ROS. Covers links, joints, syntax, xacro for simplification, and a practical example.

The Bionic Future of Prosthetics - Robotic Ankles and Exoskeletons
Pioneering bionic technology: Explore cutting-edge robotic ankles and their potential to revolutionize mobility for amputees and stroke survivors.

Can We Simulate a Real Robot?
Explore robot simulation using Isaac Sim and Python, from basic control to programming complex movements like jumps. Learn about URDF files and discover the potential of virtual robotics experimentation.
Physical and Social Human-Robot Interaction - Keynote by Giorgio Metta
Giorgio Metta discusses iCub humanoid robot research, focusing on physical and social human-robot interaction. Explores machine learning for contact interpretation and contactless cues to enhance user-robot interaction.

Robots as Future Caregivers
Exploring the potential of robots as future caregivers, envisioning innovative solutions for healthcare and elderly support.

Exoskeletons: Boosting Human Strength and Mobility
Discover how powered exoskeletons are revolutionizing human mobility and strength, with potential to help paraplegics walk again.

Advanced Prosthetic Arm Development - Dean Kamen's TEDMED Talk
Explore the development of cutting-edge prosthetic arm technology and its impact on users through inventor Dean Kamen's insightful presentation.

Detection Is Not Enough - Attack Recovery for Safe and Robust Autonomous Robotic Vehicles
Explore novel frameworks for safe attack response in autonomous robotic vehicles, enabling mission continuation despite malicious interventions through feed-forward control and sensor isolation techniques.
Analytical and Empirical Tools for Nonlinear Network Observability in Autonomous Systems
Explore nonlinear network observability in autonomous systems, covering analytical and empirical tools for sensor selection, network analysis, and applications in engineering and biology.
Abstractions for Programming Distributed Robotic Applications
Explore programming abstractions for distributed robotic systems, focusing on platform-independent control and coordination code that's portable and verifiable, using the Koord language.
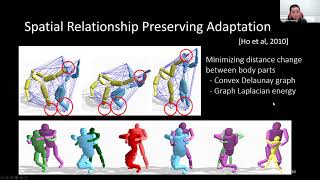
Geometric Deformation of Virtual Character Animation Using Cascaded Spacetime Constraints
Explore geometric deformation techniques for virtual character animation using cascaded spacetime constraints, focusing on motion adaptation and spatiotemporal graph representation.