Autonomous Manipulator Solutions for Mobile Robotics
Explore autonomous manipulator solutions for mobile robotics, focusing on challenges in remote environments, machine perception, and object interaction. Learn about building blocks for advanced robotic control and human-robot collaboration.
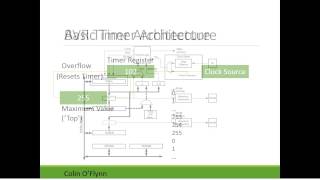
Sensors
Explore sensor technologies, echo location, timers, and practical applications in robotics, including whiskers and bump sensors for enhanced navigation and interaction.
Training and Deploying AI for Industrial Robotics - Unite Now 2020
Explore AI training for industrial robotics using Unity, featuring domain randomization and insights on shaping the future of robotics from industry experts.
Safe Learning in Robotics
Explore safe learning in robotics, covering reachable sets, collision avoidance, fast planning, and human-robot interaction. Gain insights into cutting-edge techniques for autonomous systems.
A Few Challenge Problems from Robotics
Explore challenging robotics problems, including backflips, models, perception, and optimization. Gain insights into reinforcement learning, state estimation, and physics-based approaches for advanced robotic systems.
Safety-Critical Autonomous Systems - What is Possible? What is Required?
Explore the design, challenges, and potential of safety-critical autonomous systems in aerospace, transportation, and consumer applications, focusing on verification and formal methods.

Dynamic Robot Manipulation - Learned Optimization, Deformable Materials, and the Cloud
Explore dynamic robot manipulation through integrated planning, deep learning, and cloud computing for high-speed, reliable motions in unstructured environments.
Perceptual Robot Learning - David Held, CMU
Explore innovative approaches to robot perception and planning for manipulating diverse objects, enhancing capabilities in cloth handling, articulated objects, and transparent materials.
Learning Robot Policies from Imperfect Teachers - Taylor Kessler Faulkner, UT Austin
Explore algorithms for robots learning from imperfect human teachers, addressing inattention and inaccurate information to enhance interactive Reinforcement Learning and improve human-robot teaching interactions.
Certifiable Outlier-Robust Geometric Perception - Robots that See through the Clutter with Confidence
Explore cutting-edge algorithms for robust geometric perception in robotics, enhancing safety and reliability in autonomous systems across various applications.
Towards Generalization of Precise Robot Skills - Accurate Pick-and-Place of Novel Objects
Explore precise robotic generalization for pick-and-place tasks using simulation-learned models. Discover how visuo-tactile sensing enables accurate object manipulation and placement with sub-millimeter precision for novel items.
Better Ways to Measure and Move - Joint Optimization of Agent's Physical Design and Computational Reasoning
Explore joint optimization of physical design and computational reasoning for intelligent agents, enhancing sensor networks, legged robots, and soft robotics through machine learning techniques.
Assistive Autonomy Revisited - Brenna Argall, Northwestern University
Exploring robotics autonomy to enhance human independence for those with motor impairments. Discusses challenges, research, and innovative approaches in assistive technology and rehabilitation robotics.
Robots That Talk and Learn - Shiwali Mohan, Palo Alto Research Center
Explore interactive task learning for robots, focusing on designing collaborative human-AI systems. Discover advances in enabling robots to learn new tasks through natural interactions with humans.
Object Manipulation with Physics-Based Models - Mehmet Dogar, University of Leeds
Physics-based planning for robotic object manipulation in cluttered scenes and collaborative human-robot tasks. Explores motion prediction, force stability, and human comfort constraints for advanced manipulation scenarios.
Cheetah-Inspired Robot Tails and Kalman Filtering for Hybrid Systems - Aaron Johnson, CMU
Exploring cheetah-inspired aerodynamic robot tails and state estimation for hybrid systems, enhancing agility in legged robots and improving control during discontinuous impacts.
Semantic Robot Programming and Maybe Making the World a Better Place - Chad Jenkins, U of Michigan
Explore semantic robot programming, its potential to revolutionize human-robot interaction, and the challenges in making robotics accessible to diverse users and developers.
The Power of Gradients in Inverse Dynamics Problems - Tao Du, MIT
Exploring analytical gradients in physics simulation for computational design of dynamic systems, with applications in robotics, biomechanics, and computer graphics.
MicroFPGA – The Coming Revolution in Small Electronics
Explore the potential of small FPGAs in electronics, their advantages, and applications using open-source tools and affordable development boards for high-performance, flexible projects.
Bio-Inspired Sensing
Explore bio-inspired sensing and its applications in robotics, focusing on how biological systems like the human eye inform edge detection, noise rejection, and data processing in artificial sensors.
Lessons in Making Laser Shooting Robots
Explore the journey of building laser-shooting robots, from simple beginnings to advanced designs. Learn valuable tips and lessons for creating your own competitive robot.