Programming a Self-Balancing Robot in Rust
Explore programming a self-balancing robot using Rust, covering IO abstractions, sensors, drivers, filters, and bare metal multitasking. Learn how Rust's features enhance development and program correctness.
The Birds, the Bees, and the CVEs - Understanding Novel Vulnerabilities in Critical Infrastructure
Explore strategies for assessing novel vulnerabilities in critical infrastructure, focusing on control systems and medical devices. Learn techniques to understand and mitigate risks in complex ecosystems.

What Is a PID Controller?
Comprehensive introduction to PID controllers, explaining their components, functionality, and applications in control systems. Includes practical examples and code implementation guidance.
Creating Custom Hardware Interfaces for ROS2 Control
Learn to create custom hardware interfaces for ros2_control, enabling integration of any hardware. Includes demo code walkthrough, modifications, and practical improvements for robotics projects.
How to Tune a PID Controller for an Inverted Pendulum
Practical guide to manually tuning a PID controller for an inverted pendulum system, demonstrating Arduino-Python integration and step-by-step adjustment of Kp, Ki, and Kd parameters.
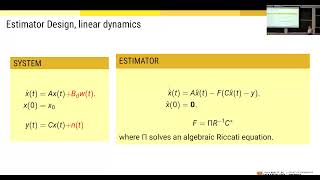
State Estimation of Complex Systems
Explore state estimation techniques for complex systems, focusing on advanced methods and applications in dynamical systems and machine learning.
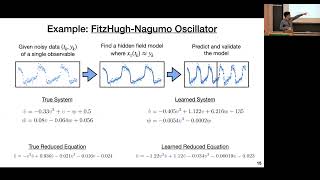
Discovering Dynamics and Parameters of Nonlinear Systems from Partial Observations
Explore techniques for uncovering nonlinear system dynamics and parameters using incomplete data, enhancing understanding of complex systems and their behavior.
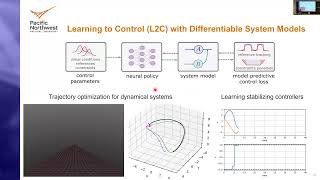
Differentiable Programming for Data-driven Modeling, Optimization, and Control
Explore data-driven modeling, optimization, and control through differentiable programming techniques in this symposium talk by Jan Drgona from Pacific Northwest National Laboratory.
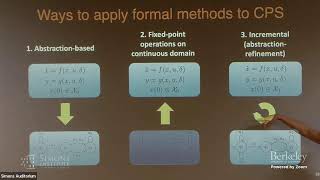
Lifting as an Abstraction for Control Synthesis in Cyber-Physical Systems
Explore control synthesis for cyber-physical systems through discrete abstractions and dynamic simplification via lifting, with insights on Koopman embeddings and potential applications.
Path Integral Control Theory
Explore path integral control theory, a powerful mathematical framework for optimal control in complex systems. Gain insights into its applications and mathematical foundations.
Artificial Neural Networks Through the Lens of Dynamical Systems Theory
Explore artificial neural networks from a dynamical systems perspective, gaining insights into their behavior and properties.
Closed Loop Response of Second Order Systems
Analyze closed loop responses of second-order systems, exploring key concepts and characteristics for enhanced system understanding and control.
Intuition Behind the Dominant and Second Poles in a Miller Compensated OTA
Explore dominant-pole compensation, phase margin, and Miller compensation in operational transconductance amplifiers. Gain insights into pole splitting for improved stability.
Stability and Learning in Strategic Queueing Systems
Explore stability and learning in strategic queueing systems with Éva Tardos. Discover how selfish behavior affects packet routing and server capacity in this insightful seminar on optimization and data analysis.
Towards $1 Robots
Explore the future of accessible robotics through innovative design, fabrication, and control methods. Learn how low-cost robots can revolutionize work, education, and play for everyone worldwide.
An Online Learning Approach to Model Predictive Control - 2019 ADSI Summer Workshop
Explore online learning approaches to Model Predictive Control with Byron Boots, focusing on algorithmic foundations and innovative applications in learning and control systems.
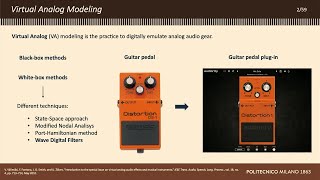
Recent Trends in Virtual Analog Modeling Based on Nonlinear Wave Digital Filters
Explore recent advancements in virtual analog modeling using nonlinear Wave Digital Filters. Gain insights into emulating complex audio circuits with multiple nonlinearities for improved stability, accuracy, and efficiency.
Non-Asymptotic Analysis of a Classical System Identification Algorithm - 2019 ADSI Summer Workshop
Explore non-asymptotic analysis of classical system identification with Necmiye Ozay, delving into advanced algorithmic foundations for learning and control in this insightful conference presentation.
Stable Adaptation and Learning in Nonlinear Systems and Neural Networks
Explore nonlinear systems tools for insights on collective computation and learning in large dynamical networks, focusing on stable adaptation and implicit sparse regularization.

Probabilistic and Machine Learning Approaches for Autonomous Robots and Automated Driving
Explore probabilistic and machine learning approaches for autonomous robots and automated driving, focusing on robust perception and action execution in uncertain environments.

Building Blocks of Generalizable Autonomy
Explore key aspects of generalizable autonomy in robotics, including representational biases, causal inference, and interactive policy learning under uncertainty for efficient and adaptable AI systems.