Introduction to Evolutionary Game Theory - Classes 3 and 4
Explore evolutionary game theory applications in socio-economic complexity through advanced concepts and mathematical models.
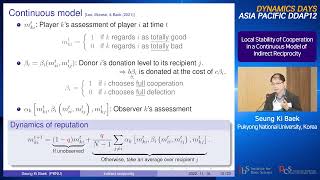
Local Stability of Cooperation in a Continuous Model of Indirect Reciprocity
Explore stability of cooperation in indirect reciprocity using continuous variables for reputation and behavior. Analyze Image Scoring vs Simple Standing and derive conditions for maintaining cooperation.
Introduction to Type-III Compensator
Explore Type-III Compensator fundamentals, understanding its principles, applications, and design considerations in control systems engineering.
Time Domain Analysis of a Simple PLL
Analyze a simple PLL mathematically and through simulation, focusing on initial frequency error in the time domain.
Designing a Linear Regulator - Negative and Positive Feedback
Explore linear regulator design, focusing on negative and positive feedback mechanisms for effective voltage regulation and circuit stability.
First Order Systems and Phase Margin
Explore first order systems and phase margin concepts in control engineering, enhancing understanding of system stability and performance.
Digital LDO: Techniques to Avoid Limit Cycle Oscillations
Explore techniques to prevent limit cycle oscillations in digital LDOs, enhancing stability and performance in power management systems.
Phase Margin Example in Dominant-Pole and Miller Compensation
Explore dominant-pole compensation, phase margin, and Miller compensation techniques to enhance your understanding of electronic circuit stability and performance.
Introduction to Type-II Compensation
Learn about Type-II compensation techniques, their applications, and how they enhance system stability and performance in control engineering.
Finding the Poles of the Error Amplifier - Part 2
Explore error amplifier pole identification techniques, enhancing understanding of circuit analysis and design for improved electronic system performance.
Classification of Pulse Width Modulators
Learn about different types of pulse width modulators, their characteristics, and applications in power electronics. Gain insights into modulation techniques for efficient control of electrical systems.
Frequency Acquisition in Type II PLLs
Explore frequency acquisition in Type II PLLs, focusing on proportional and integral paths, pull-in voltage, and amplification techniques.
Simple Implementation of a Phase Locked Loop
Explore a simple circuit implementation of basic PLL blocks: phase error detector, loop filter, and voltage controlled oscillator.
From State Space Control to Intelligent Machines - A Five-Decade Journey in Mechanical Systems Control
Explore a five-decade journey in mechanical systems control, from state space theory to intelligent industrial robots and autonomous driving. Gain insights from Masayoshi Tomizuka's research at UC Berkeley.
Nuts and Bolts of Modern State Space Models - Part I
Explore state space models for analyzing sequential data, covering foundations, algorithms, and applications using the dynamax library. Learn to uncover latent states in high-dimensional measurements.
Learning to Control in Power Systems: Design and Analysis Guidelines for Concrete Safety Problems
Explore AI safety considerations in power systems control, focusing on integrating renewable energy and addressing uncertainty through case studies and design guidelines.
Model Predictive Control Design: Multiparametric Optimization and Workflows
Design model predictive controllers using multiparametric optimization. Explore formulation, workflows, and related functionality in this concise presentation.
Control Systems: An Overview - From Differential Equations to Controller Design and Deployment
Explore control systems, from differential equations to controller design and deployment, with streamlined workflows for effective system management and optimization.
Calculus and Control Systems in Wolfram Language
Master calculus and control systems using Wolfram Language, exploring state-space models, transfer functions, and discrete-time systems for efficient problem-solving.
Symbolic Computations and Dynamic Visualization in Robotics Research and Education
Explore symbolic computations and dynamic visualizations for robotics research and education using Wolfram Mathematica, enhancing understanding of complex robotic systems.
Nonlinear Stochastic Hybrid Optimal Control with Fixed Terminal States
Explore novel approaches for stochastic systems with fixed terminal states. Learn about Terminally Constrained Stochastic Minimum Principle and Hamilton-Jacobi equations for optimal control.