A Few Challenge Problems from Robotics
Explore challenging robotics problems, including backflips, models, perception, and optimization. Gain insights into reinforcement learning, state estimation, and physics-based approaches for advanced robotic systems.
Cheetah-Inspired Robot Tails and Kalman Filtering for Hybrid Systems - Aaron Johnson, CMU
Exploring cheetah-inspired aerodynamic robot tails and state estimation for hybrid systems, enhancing agility in legged robots and improving control during discontinuous impacts.
PID Controllers
Learn about PID controllers: their components, applications, and how they achieve stable control systems. Explore mathematical models and live simulations to understand this powerful algorithm.
Cyber-Physical Security - Dr. Bruce DeBruhl
Explore cyber-physical security, including system models, attack examples, and modern contexts. Learn about securing critical infrastructure and emerging challenges in networked control systems.
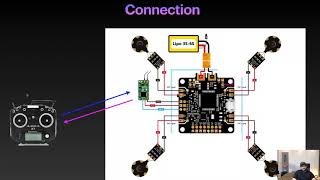
Introduction to FPV Drones
Explore FPV drone flight controllers, IMUs, sensor fusion, control systems, and PID. Learn about digital signal processing, filtering, and firmware for advanced drone piloting.
Polynomial Approximation of Random PDEs by Discrete Least Squares with Observations
Polynomial approximation of random PDEs using discrete least squares with random point observations. Explores stability, error bounds, and optimal index set selection for metamodel construction in high-dimensional parameter spaces.
Introduction to Geometric Control Theory - Lecture 4
Explore geometric control theory's advanced concepts, focusing on mathematical foundations and practical applications in dynamic systems and optimization.
Introduction to Geometric Control Theory - Lecture 3
Explore advanced concepts in geometric control theory, focusing on mathematical principles and applications in dynamic systems and optimization.
Introduction to Geometric Control Theory - Part II
Explore advanced concepts in geometric control theory, focusing on mathematical principles and applications in dynamic systems and optimization.
Introduction to Geometric Control Theory - Lecture 1
Explore geometric control theory fundamentals with expert Andrei Agrachev, covering key concepts and applications in this comprehensive lecture from ICTP Mathematics.
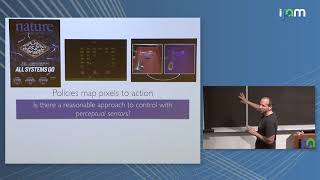
Trying to Make Sense of Control from Pixels
Explores challenges in merging machine learning with control systems, focusing on autonomous vehicles using vision. Discusses uncertainty quantification, robust controller design, and performance guarantees.
Learning Control from Minimal Prior Knowledge
Explore neural reinforcement learning for autonomous control, focusing on data-efficient off-policy learning and effective exploration techniques for complex tasks in simulation and reality.
Tame Control Theory - Lecture 5
Explore advanced concepts in tame control theory, focusing on phenomena over real fields. Delve into graduate-level mathematical analysis and applications.
Tame Phenomena Over the Real Field - Graduate Course Lecture 1
Explore fundamental concepts of tame control theory, focusing on real field applications and advanced mathematical principles in this graduate-level lecture.
Learning Linear Dynamical Systems with Hankel Nuclear Norm Regularization
Explore finite-sample analysis and insights for learning low-order linear dynamical systems using Hankel nuclear norm regularization, with applications in control and reinforcement learning.
Vulnerabilities of Control Systems in Drinking Water Utilities - Notacon 9
Explore vulnerabilities in drinking water control systems, potential cyber threats, and necessary security measures to protect critical water infrastructure.
The Gift of Feedback - Enhancing Application Security
Discover how to implement next-generation security by leveraging feedback, pushing security left, and making it consumable. Learn strategies to engage developers and address the challenges of securing complex software workloads.
Exploring the World of Coupled Oscillators - Jürgen Moser Lecture
Pioneering insights into nonlinear systems and oscillatory dynamics, exploring emergent phenomena, synchrony, and chaos. Retrospective on key contributions to the field of coupled oscillators and dynamical reduction.
Understanding the Impact of Critical Vulnerabilities in Critical Infrastructure: A Detective Story
Explore strategies for assessing and mitigating critical infrastructure vulnerabilities, focusing on novel threats and their potential ecosystem-wide impacts across various sectors.
North American Power-Grid Network - Failures and Opportunities
Explore cascading failures in the U.S.-South Canada power grid, identifying vulnerable components and discussing mitigation strategies for improved grid resilience and renewable energy integration.
Building Dynamic Robots - Marc Raibert, Boston Dynamics
Exploring the future of dynamic robots with Marc Raibert, discussing advancements in hardware, control systems, and real-world applications. Includes insights on Boston Dynamics' innovations and a live robot demonstration.