EI Seminar - Recent Papers in Embodied Intelligence
Explore cutting-edge research in embodied intelligence, covering topics like experiment design, neuro-symbolic models, robot design, speech recognition, and social perception.
Swarms of Small Flying Robots - Advances in UAV Technology and Applications
Explore the fascinating world of small flying robots and swarms, their applications, and the cutting-edge research behind their development and autonomous capabilities.
Integrated Task and Motion Planning in Belief Space
Explore integrated strategies for planning, perception, and action in complex mobile manipulation domains using belief space planning and hierarchical goal regression.
A Few Challenge Problems from Robotics
Explore challenging robotics problems, including backflips, models, perception, and optimization. Gain insights into reinforcement learning, state estimation, and physics-based approaches for advanced robotic systems.
Cheetah-Inspired Robot Tails and Kalman Filtering for Hybrid Systems - Aaron Johnson, CMU
Exploring cheetah-inspired aerodynamic robot tails and state estimation for hybrid systems, enhancing agility in legged robots and improving control during discontinuous impacts.
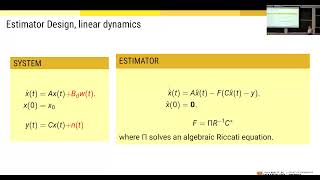
State Estimation of Complex Systems
Explore state estimation techniques for complex systems, focusing on advanced methods and applications in dynamical systems and machine learning.

Probabilistic and Machine Learning Approaches for Autonomous Robots and Automated Driving
Explore probabilistic and machine learning approaches for autonomous robots and automated driving, focusing on robust perception and action execution in uncertain environments.
Nuts and Bolts of Modern State Space Models - Part I
Explore state space models for analyzing sequential data, covering foundations, algorithms, and applications using the dynamax library. Learn to uncover latent states in high-dimensional measurements.
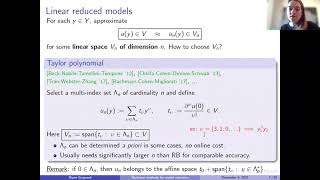
Nonlinear Reduced Models for Parametric/Random PDEs
Explore efficient techniques for constructing reduced models of parametric/random PDEs, focusing on error estimation, library construction, and practical applications in thermal systems and state estimation.
Multisymplectic Unscented Kalman Filter for Geometrically Exact Beams
Explore advanced filtering techniques for geometrically exact beam models using multisymplectic unscented Kalman filters in structural engineering applications.
Fast Probabilistic Inference for ODEs with ProbNumDiffEq.jl
Explore probabilistic ODE solvers with ProbNumDiffEq.jl. Learn Bayesian inference for numerical problems, implementation details, and future prospects in the Julia ecosystem.
Computational Principles of Sensorimotor Control - Lecture 1
Explore computational principles of sensorimotor control, including optimal feedback control, state estimation, motor learning, and Bayesian decision theory in human movement and robotics.
Application of Particle Filters on Data Assimilation
Explore particle filters in data assimilation, a powerful technique for integrating observations and forecasts to estimate atmospheric states and uncertainties in weather and climate modeling.
Efficient Visual Avoidance and Control for UAVs with Embedded GPUs
Explore efficient visual navigation for UAVs using embedded GPUs, covering odometry, mapping, planning, and control for compact, autonomous quadrotors capable of GPS-denied indoor flight and obstacle avoidance.
The Hadamard Test - Quantum Computer Programming - Lesson 82
Explore the Hadamard Test in quantum computing, learning to estimate unitary rotations of quantum states in this concise, expert-led lesson.
ModelPredictiveControl.jl - Advanced Process Control Using JuMP
Learn to design model predictive controllers using ModelPredictiveControl.jl, an open-source package for advanced process control based on JuMP, featuring nonlinear state estimation and visualization tools.
Real-World AI: Risk and Robustness in Reinforcement Learning and Kalman Filtering
Explore real-world applications of AI through risk-aware reinforcement learning and robust Kalman filtering, focusing on practical challenges and solutions for handling uncertainties in AI systems.
Low Complexity Optimal Policies for Networked Control Systems
Explore optimal scheduling policies for wireless networked control systems, focusing on channel observation, risk-sensitive cost criteria, and half-duplex controller scenarios in communication networks.