Android + Pepper: Developing Interactive Applications for Humanoid Robots
Explore the capabilities and opportunities of developing Android applications for Pepper, the humanoid robot. Learn about creating custom animations, specialized dialogues, and see Pepper in action.
Embodiment in Artificial Intelligence - Session 8
Explore the concept of embodiment in AI and robotics, examining how physical form influences cognitive processes and interactions with the environment.
Perception and Manipulation in Robotics - Session 14
Explore cutting-edge advancements in robotic perception and manipulation techniques, focusing on innovative approaches to enhance machine vision and dexterity in various applications.
Embodiment in Artificial Intelligence - Session 15
Explore advanced concepts of embodiment in AI and robotics, delving into the integration of physical form and cognitive processes for enhanced machine intelligence.
Building Thoughtful Robotics - Addressing Racial Biases and Inequities
Leaders of "Black in Robotics" advocate for addressing racial biases in robotics development, emphasizing diversity in creators and thoughtful consideration of potential impacts on all groups before deploying new technologies.
Communication Through Touch - From Babies to Social Robots
Explore the fascinating world of tactile communication, from infant development to cutting-edge social robotics, and its impact on human interaction and technology.
NAO Humanoid Robot - Introduction and Applications
Explore the fascinating world of humanoid robotics with a focus on the NAO robot, its capabilities, and applications in Java programming.
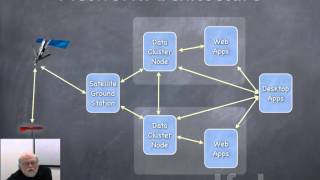
Robots and Oceans: Deep Sea Robotics with Liquid Robotics
Explore deep sea robotics with Java pioneer James Gosling, discussing Liquid Robotics' innovative ocean-monitoring technology, its applications, and network architecture.
Beyond Language: Scaling up Robot Ontogeny
Explore cutting-edge research on scaling robot ontogeny, focusing on advancements beyond language processing for more sophisticated artificial intelligence development.
Hands-on Introduction to Telepresence for Kubernetes Development
Hands-on guide to Telepresence for local Kubernetes development. Learn installation, networking, and intercepts to streamline microservices workflow and boost productivity.
Drone vs Tesla: Exploiting Vulnerabilities in Automotive Systems
Explore the security vulnerabilities in Tesla vehicles through a drone-based attack demonstration, highlighting potential risks and countermeasures in automotive cybersecurity.
The Future of Cyber-Autonomy
Exploring autonomous cybersecurity systems like Mayhem, their potential to revolutionize software security, and implications for future defense strategies against machine-speed attacks.
Creating Custom Hardware Interfaces for ROS2 Control
Learn to create custom hardware interfaces for ros2_control, enabling integration of any hardware. Includes demo code walkthrough, modifications, and practical improvements for robotics projects.
Simplified Solutions - Easy-to-Use AI for Embedded Applications
Discover simplified AI solutions for embedded systems, focusing on reducing complexity and optimizing for IoT smart sensors in various applications like wearables, robotics, and automotive.
How to Tune a PID Controller for an Inverted Pendulum
Practical guide to manually tuning a PID controller for an inverted pendulum system, demonstrating Arduino-Python integration and step-by-step adjustment of Kp, Ki, and Kd parameters.
Guardians of Cybersecurity - Deploying IoT Devices via Drones and Dropboxes
Explore the cybersecurity implications of drones carrying hacking devices, discussing potential threats and the need for increased awareness in this emerging field of IoT and aerial technology.
Drones, RemoteID and the Thrilling Future of UAS Flight
Explore RemoteID technology reshaping drone flight, focusing on safety, security, and regulatory compliance. Discover current applications and challenges in the thrilling future of UAV aviation.
Scan, Patch, VEX - Using Open Source Tools to Manage Vulnerabilities in Containers
Learn to manage vulnerabilities in cloud-native environments using open-source tools like Trivy and Copacetic, and standards like VEX. Improve security across development, testing, and production.
How to Generate VEX Automatically for Your Project
Learn to automate VEX generation for Kubernetes workloads, reducing false positives in security scans and streamlining vulnerability management using Kubescape and a new GitHub Action.
Linear Operator Theoretic Framework for Data-Driven Optimal Control
Explore a novel approach to data-driven optimal control using linear operator theory, presented by Umesh Vaidya from Clemson University at the Fourth Symposium on Machine Learning and Dynamical Systems.
Automated End-to-End VEX Streams You Can Trust
Explore automated VEX streams for trusted vulnerability communication. Learn to build end-to-end systems using OpenVEX, enhancing software security without human intervention.