SMARS SG90 Servos, PCA9685 and Arduino - Programming Robots
Learn to program SMARS robots using Arduino, SG90 servos, and PCA9685 modules. Covers servo basics, wiring, coding, and introduces SMARS_Library for Python, enhancing your robotics skills.
SMARS - MPU-6050 & GY-271, Arduino Programming Robots
Learn to program SMARS robots with Arduino, connecting DOF sensors for accurate movement, collision detection, and 3D positioning. Gain practical skills in robotics and sensor integration.
SMARS HC-SR07 Range Finder Arduino Programming - Sensors
Learn to program an Arduino-controlled SMARS robot with a range finder sensor, enabling object detection and avoidance. Gain hands-on experience in sensor integration and basic robotics.
SMARS Motor Control Arduino Programming - Movement
Learn to program SMARS robots using Arduino, covering basics of motor control and movement. Hands-on coding session included, suitable for beginners in robotics and Arduino programming.
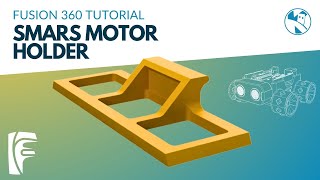
SMARS Fusion 360 Design - Motor Holder
Design tutorial for creating SMARS robot motor holders in Fusion 360, covering sketching, dimensioning, and 3D modeling techniques. Learn to craft printable parts for building low-cost, Arduino-powered robots.
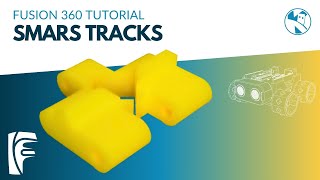
SMARS Fusion 360 Design - Tracks
Design SMARS robot tracks using Fusion 360, covering wheel insertion, sketching, measurement, and motor holder creation. Ideal for 3D printing enthusiasts and robotics hobbyists.
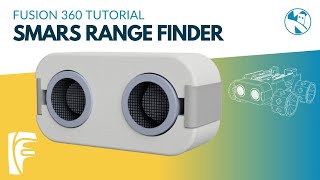
SMARS Robot Range Finder Module Design in Fusion 360
Learn to design a range finder module holder for SMARS robots using Fusion 360, enabling creation of low-cost, open-source robots with 3D printing and Arduino components.
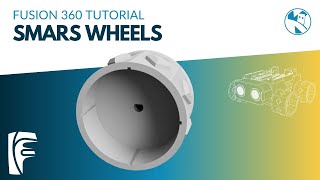
SMARS Fusion 360 Design - Wheels
Learn to design SMARS robot wheels using Fusion 360. Step-by-step guide covers sketching, extruding, cutting, and assembling, perfect for 3D printing enthusiasts and robotics hobbyists.
SMARS Fusion 360 Design - Chassis
Learn to design a SMARS robot chassis in Fusion 360. Step-by-step guide covers sketching, shell creation, cutouts, motor holders, Arduino slots, and battery placement for both quad and wheeled versions.
Author Interview - SayCan - Do As I Can, Not As I Say - Grounding Language in Robotic Affordances
Explore SayCan, a groundbreaking approach combining language models with robotic skills for complex task execution. Learn about its development, challenges, and future implications in AI and robotics.
Do As I Can, Not As I Say - Grounding Language in Robotic Affordances
Explanation of SayCan, a system combining language models with robotic skills for real-world task execution. Covers methodology, implementation, and experimental results for complex instruction following.

Harmonic vs Cycloidal Drive - Torque, Backlash and Wear Test
Comprehensive comparison of 3D-printed harmonic and cycloidal drives, exploring design, assembly, efficiency, accuracy, and durability. Includes practical tips for 3D printing and robotics applications.

Path Planning - A* (A-Star) Algorithm Implementation in C++
Learn to implement the A* pathfinding algorithm in C++, with a step-by-step tutorial covering key concepts, practical coding, and visual demonstrations at the command prompt.
Using the BLE Bluetooth Module for Robotic Control
Learn to program an Elegoo Smart Car using BLE Bluetooth for robotic control, covering speed, distance, and turning. Gain hands-on experience with Arduino and Bluetooth integration for advanced robotics projects.
Using the BLE Bluetooth Module to Control the Elegoo Smart Car
Learn to control the Elegoo Smart Car using BLE Bluetooth module, including app setup, pairing, and Arduino programming for remote operation via smartphone.
Robotics Training - Controlling the Elegoo Smart Car With IR Remote
Learn to program an Elegoo Smart Car to respond to IR remote commands, enabling forward, backward, left, and right movements within a 10-foot range. Hands-on tutorial with code examples and troubleshooting tips.
Controlling DC Motor Speed with the L298N
Learn to control DC motor speed using L298N in robotics, including programming core motion functions for forward, backward, turning, and stopping movements.
Fundamentals of Robot Motor Control Using L298N Module
Learn to control DC motors using L298N module for robot movement, including forward, backward, and turning. Hands-on Arduino programming for practical robotics applications.
Axis IMU - Accurate and Stable Tilt Using Accelerometers, Gyros and a Complimentary Filter
Learn to achieve stable and responsive tilt measurements using accelerometers, gyros, and a complimentary filter for accurate pitch and roll approximation in IMU applications.

Mecanum Wheel Robot Car & ESP-NOW Remote
Learn to build and control a Mecanum wheel robot car using ESP32 boards, featuring ESP-NOW communication, joystick control, TFT display, and NeoPixel LEDs. Gain hands-on experience with advanced robotics concepts.

Driving DC Motors with Microcontrollers
Learn to control DC motors using various driver modules and Arduino. Explore hookup methods, coding techniques, and practical demonstrations for both small and large motors.