Introduction to PID Loops
Learn the fundamentals of PID loop control, including configuration, tuning methods, and practical applications. Gain insights from an experienced engineer to improve your process control skills.
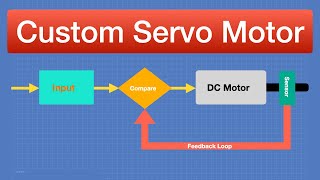
Build a Custom Servo Motor with a DC Motor
Learn to convert a DC motor into a custom servo motor using a Seeeduino XIAO and PID controllers. Gain hands-on experience in building precise motor control systems for various applications, from robotics to DIY projects.
Building the MeArm Robotic Arm
Comprehensive guide to assembling the MeArm robotic arm, including servo calibration, step-by-step construction, and Arduino control. Highlights common errors and provides practical tips for successful assembly.
Extremum Seeking Control in Simulink
Explore extremum-seeking control in Simulink, learning to build control topology, set initial conditions, and optimize static objective functions through practical demonstrations.

Examples of Nonlinear Systems - Particle in a Potential Well
Explore nonlinear systems through the particle in a potential well example, covering Euler-Lagrange equations, vector fields, phase portraits, and damping in engineering mathematics.
How We're Trying to Do Docs Better
Explore Xata's approach to creating fast, up-to-date, and impactful documentation for an enhanced developer experience, featuring static site generation and code generation techniques.
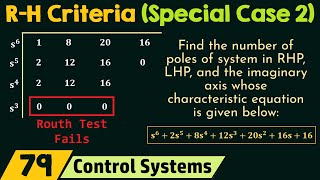
Routh-Hurwitz Criteria - Special Case 2
Explore the Routh-Hurwitz Criteria's special case 2, focusing on its effects, solutions, and practical applications through detailed explanations and examples.
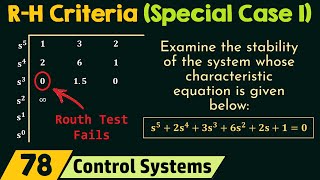
Routh-Hurwitz Criteria - Special Case 1
Explore special cases of Routh-Hurwitz criteria, focusing on zero elements in the first row and methods to overcome this issue using epsilon and inverse polynomial techniques.
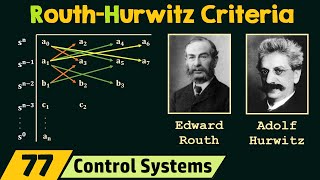
Routh-Hurwitz Criteria
Explore stability analysis in control systems using Routh-Hurwitz criteria. Learn necessary conditions, array formation, and practical examples for effective system evaluation.
Translational Mechanical Systems
Solve a complex translational mechanical system problem, mastering free body diagrams, force polarity conventions, and equations of motion for two-degree freedom systems.
Introduction to Signal Flow Graphs
Learn to construct and analyze Signal Flow Graphs (SFGs) for control systems, covering key elements, conversion from block diagrams, and practical examples to enhance understanding.
Integrated Task and Motion Planning in Belief Space
Explore integrated strategies for planning, perception, and action in complex mobile manipulation domains using belief space planning and hierarchical goal regression.
Challenging Path to Creating Autonomous and Controllable Microrobots
Exploring breakthroughs in microrobotics: autonomous crawling, controllable flying, and ultrafast SMA-driven robots. Innovations in power, actuation, and control push boundaries of insect-scale robotics towards true artificial insects.

Planning and Control
Explore state transition equations, numerical examples, and PyTorch implementations for optimal control in planning and control systems, with a focus on the Kelley-Bryson algorithm and cost considerations.
An Informational Perspective on Uncertainty in Control
Explore the mathematical challenges in real-time decision making, focusing on informational perspectives of uncertainty in control systems and their applications.
Control Bootcamp - Cruise Control Example with Proportional-Integral Control
Explore proportional-integral control in cruise control systems, reducing steady-state errors using a sophisticated automobile model. Gain practical insights into advanced control techniques.
Stabilization of Nonlinear Systems by Oscillating Controls with Application
Explore nonlinear system stabilization using oscillating controls, with applications in nonholonomic and fluid dynamics. Covers control design, Lie brackets, and energy cascades.
Claire Tomlin- "Towards Real-Time Reachability"
Explore real-time reachability in high-dimensional systems, focusing on Hamilton-Jacobi PDEs, hybrid systems, and applications in traffic patterns and autonomous vehicles.

Learning-Based Model Predictive Control - Towards Safe Learning in Control
Explores integrating learning techniques with optimization-based control for safe, high-performance systems. Discusses methods for data-driven modeling, safety filters, and constraint satisfaction in robotics applications.
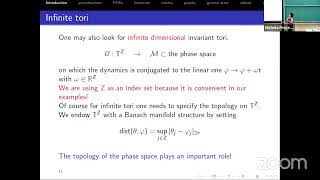
Stability and Recursive Solutions in Hamiltonian PDEs
Explore stability and recursive solutions in Hamiltonian PDEs, focusing on oscillating motions near elliptic fixed points, KAM theory applications, and the interplay between chaotic and recursive phenomena.
Interactive Error Resilience Beyond
Explore advanced techniques for error-resilient communication, including interactive protocols and coding schemes that enhance message exchange in noisy channels.