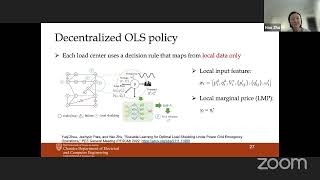
Graph Neural Networks for Learning Nonlinear Power System Operations
Explore nonlinear power system operations using graph neural networks, covering optimization, computational benefits, and emergency response in power flow models.
Optimization-in-the-Loop AI for Energy and Climate - IPAM at UCLA
Optimization-in-loop AI framework for climate action: enhancing ML models with physics, constraints, and decision-making processes for energy grids, building efficiency, and more.
Working Memory Influences Reinforcement Learning Computations in Brain and Behavior
Explore how working memory influences reinforcement learning in the brain, examining experimental results, genetic factors, and EEG data to uncover neural mechanisms of learning.
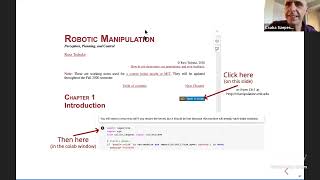
A Few Challenge Problems from Robotics
Explore challenging robotics problems, including backflips, models, perception, and optimization. Gain insights into reinforcement learning, state estimation, and physics-based approaches for advanced robotic systems.
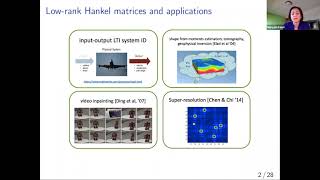
Learning Linear Dynamical Systems with Hankel Nuclear Norm Regularization
Explore finite-sample analysis and insights for learning low-order linear dynamical systems using Hankel nuclear norm regularization, with applications in control and reinforcement learning.
Mastering the Maze - Reinforcement Learning for Automated Penetration Testing
Explore how reinforcement learning can revolutionize penetration testing by automating lateral network movement and identifying attack vectors, enhancing efficiency in cybersecurity assessments.
Connections between POMDPs and Partially Observed N-Player Mean-Field Games
Explore connections between POMDPs and partially observed n-player mean-field games. Gain insights into discrete-time models, mean-field observability, and equilibrium existence in symmetric settings.
Path Integral Control Theory
Explore path integral control theory, a powerful mathematical framework for optimal control in complex systems. Gain insights into its applications and mathematical foundations.
Policy Learning in Spatial Action Spaces for Robotic Manipulation
Explore innovative approaches to robotic policy learning in spatial action spaces for complex manipulation tasks, addressing challenges and evaluating solutions in simulated and physical environments.
Scaling Probabilistically Safe Learning to Robotics
Explores advancements in safe robot learning, focusing on imitation learning theory, scalable reward inference, and efficient policy evaluation to enable real-world deployment with safety guarantees.
Feedback Design Principles for Efficient and Reliable Robot Learning
Exploring fusion of feedback control and reinforcement learning for efficient, reliable robot learning. Discusses reward shaping, co-design of controllers and algorithms, and future directions in robotics.
Open Source Summit and Embedded Linux Conference Keynotes - Day 3
Explore cutting-edge open-source technologies through keynotes on cloud-native projects, safety-critical applications, infrastructure modernization, and RISC-V, featuring industry experts and innovative case studies.
ALOHA and ACT: Advancing Robot Learning - Research Presentation 1
Explore ALOHA and ACT methodologies for robotic learning, presented by Alexander Soare. Gain insights into cutting-edge research and advancements in robot manipulation techniques.
PhishDefend - A Reinforcement Learning Framework for AI-Augmented Phishing Detection and Response
Explore a reinforcement learning framework for measuring AI-augmented phishing detection and response, enhancing cybersecurity strategies against evolving threats.

Building Blocks of Generalizable Autonomy
Explore key aspects of generalizable autonomy in robotics, including representational biases, causal inference, and interactive policy learning under uncertainty for efficient and adaptable AI systems.
LLaRA: Supercharging Robot Learning Data for Vision-Language Policy
Enhance robotic decision-making using LLMs and VLMs. Learn to formulate actions as conversation pairs and incorporate auxiliary data for improved performance in simulated and real-world tasks.
Safe Learning in Robotics
Explore safe learning algorithms for robots in complex environments. Discover data-efficient, online methods guaranteeing safety and adaptability for real-world applications in robotics and AI.
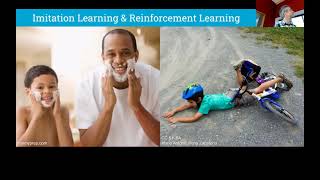
Robots Learning Through Interaction
Explore robot learning through interaction, covering supervised, imitation, reinforcement, and interactive learning methods. Gain insights into motor skill acquisition and human-robot collaboration.
Policy Revision Dynamics and Algorithm Design in Stochastic and Mean-Field Games
Explore policy dynamics and algorithm design in stochastic and mean-field games, focusing on decentralized learning algorithms for multi-agent systems and near-equilibrium convergence.
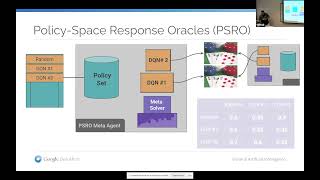
Combining Tree-Search, Generative Models, and Nash Bargaining Concepts in Game-Theoretic Reinforcement Learning
Explore game-theoretic reinforcement learning combining tree-search, generative models, and Nash bargaining concepts for multiagent scenarios and negotiation games.
Foundation Reward Models for General Robot Skill Acquisition
Explore foundation reward models for general robot skill acquisition, leveraging non-robot data to enhance adaptability in unstructured environments.