
Reinforcement Learning
Explora el Aprendizaje por Refuerzo, desde métodos básicos hasta redes neuronales y aplicaciones en dinámica de fluidos y control, en esta serie de 3.5 horas por Steve Brunton.
The Challenges of Model-Based Reinforcement Learning and How to Overcome Them - Csaba Szepesvári
Explore challenges in model-based reinforcement learning, including modeling errors and efficient planning, and discover strategies to overcome them in complex environments.
Deep Reinforcement Learning in the Real World - Sergey Levine
Explore deep reinforcement learning applications in real-world scenarios, focusing on off-policy methods, model-free and model-based approaches, and their practical implementations in robotics and manipulation tasks.
Mastering Atari with Discrete World Models - Machine Learning Research Paper Explained
Explore cutting-edge reinforcement learning with DreamerV2, a model-based AI agent achieving human-level performance on Atari games using discrete world models and latent space predictions.
Imagination-Augmented Agents for Deep Reinforcement Learning
Explore innovative deep reinforcement learning architecture combining model-free and model-based approaches for improved performance and efficiency in complex environments.
Partially Observable RL
Explore partially observable reinforcement learning, covering Markov decision processes, hidden Markov models, and belief monitoring in this comprehensive lecture.
Model-Based RL
Explore model-based reinforcement learning, including complex models, Dyna algorithm, search trees, and Monte Carlo methods for effective planning and decision-making.
Model-Based Reinforcement Learning with Value-Targeted Regression
Explore model-based reinforcement learning with value-targeted regression, covering episodic RL, UCRL, deterministic systems, and the MatrixRL algorithm.
Introduction to Reinforcement Learning
Explore reinforcement learning's evolution, breakthroughs, and applications in AI, from board games to robotics. Gain insights into key concepts, formulations, and future directions in this rapidly advancing field.
RL Foundation Models Are Coming!
Explore DeepMind's AdA algorithm, combining meta-learning, attention, and curriculum learning for advanced reinforcement learning. Discover promising results and future prospects in this emerging field.
SINDy-RL: Interpretable and Efficient Model-Based Reinforcement Learning
Explores SINDy-RL, a framework combining sparse identification of nonlinear dynamics with reinforcement learning for efficient, interpretable control policies in complex environments.
Generalizable Autonomy for Robot Manipulation
Explore generalizable autonomy in robot manipulation through imitation learning, visuo-motor policies, and reinforcement learning techniques. Discover innovative approaches for achieving adaptable and efficient robotic systems.
Decision Awareness in Reinforcement Learning - End-to-End Optimization Approaches
Explore decision awareness in reinforcement learning, covering control-oriented models, neural ODEs, and computational challenges. Gain insights into advanced techniques for optimal decision-making.
Hierarchical Imitation Learning with Vector Quantized Models
Learn hierarchical imitation learning techniques using vector quantized models for complex decision-making tasks, exploring subgoal identification and planning strategies to outperform expert demonstrations.
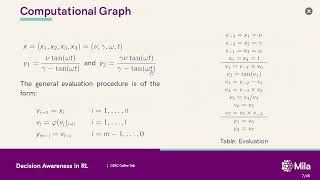
Decision Awareness in Reinforcement Learning
Explore decision awareness in reinforcement learning, focusing on control-oriented transition models and neural ODEs for nonlinear trajectory optimization. Discuss computational challenges and scaling solutions.