From State Space Control to Intelligent Machines - A Five-Decade Journey in Mechanical Systems Control
Explore a five-decade journey in mechanical systems control, from state space theory to intelligent industrial robots and autonomous driving. Gain insights from Masayoshi Tomizuka's research at UC Berkeley.
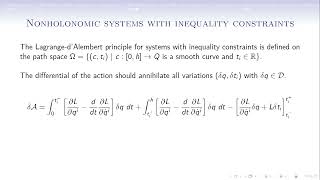
Nonholonomic Systems with Inequality Constraints
Explore nonholonomic systems with inequality constraints, delving into advanced concepts and applications in control theory and robotics.
Sensitivity-Based Design Methods for Improved Control Performance
Explore sensitivity-based design methods for improved control performance in unstable and invertible plants, focusing on fast robust control and multivariable systems.
Cohesive Games and Lessons Learned from the Field Theory of Games
Explore the Field Theory of Games, its application using Wolfram Language, and key insights on dynamic decision processes and cohesive games.
Equivalence Between Contraction and Koopman Approaches and Its Application in Nonlinear System Identification
Explore connections between Koopman operator and contraction analysis frameworks for nonlinear systems. Learn a new data-driven method for stable model learning using Koopman embeddings.
Guaranteed Cost Equilibrium in Infinite Horizon Linear-Quadratic Differential Games - Seminar
Explore output feedback guaranteed cost equilibrium in infinite-horizon linear-quadratic differential games, focusing on applications in engineering and multi-agent systems.
Hierarchical Perspective on Robotic Control
Explore hierarchical control strategies for complex robotic systems, focusing on dynamically stable behaviors in 3D hopping and planar bipedal robots. Learn about geometric and nonlinear control in hierarchical architectures.
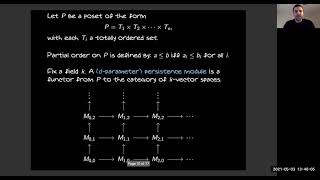
L-P Metrics on Multiparameter Persistence Modules
Explores generalizations of p-Wasserstein distance for multi-parameter persistence modules, introducing d_I^p and d_M^p metrics. Examines their properties and applications in topological data analysis.
Meeting the Integration Challenge - Optimizing Data and Design for Real-World Applications
Explore industry approaches to data integration for new applications, examining the interplay between computer science, control theory, and adaptive control in both online and offline contexts.
The Harder-Narasimhan Filtration and Stability Conditions for Vector Bundles
Delve into the mathematical theory of stability conditions and Harder-Narasimhan filtration for vector bundles, exploring their applications in geometric invariant theory and moduli spaces.

Solving Systems of Differential Equations with Eigenvalues and Eigenvectors
Learn to solve systems of linear ODEs using eigenvalues and eigenvectors. Covers problem setup, solution methods, and intuitive interpretation, with code examples in Python and MATLAB.
Solving High Dimensional HJ Equations Using Generalized Hopf-Lax Formulas vs Using Machine Learning
Explore advanced techniques for solving high-dimensional Hamilton-Jacobi equations, comparing generalized Hopf-Lax formulas with machine learning approaches in control and differential games.
Model Theory - From Logic to Geometric Stability Theory and O-Minimality I
Explore model theory principles, focusing on o-minimality and stability theory, with applications to complex geometry and arithmetic aspects.
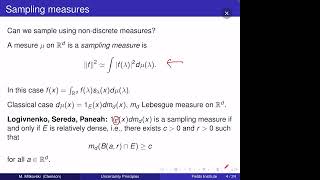
Sampling, Interpolation, and Uncertainty
Explore sampling theory, interpolation techniques, and uncertainty principles in function spaces, with applications in signal processing and control theory.
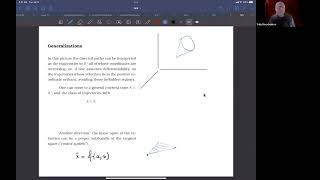
Linear Obstacles in Linear Systems and Ways to Avoid Them
Explore topology in control theory, focusing on obstacle-avoiding paths and cohomology rings using homotopy limits. Gain insights into theoretical computer science applications.
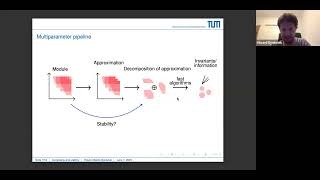
Stabilizing Decomposition of Multiparameter Modules
Explores stability theories for multiparameter module decomposition, addressing challenges and presenting recent findings. Discusses potential strengthening of stability results for staircase decomposable modules.
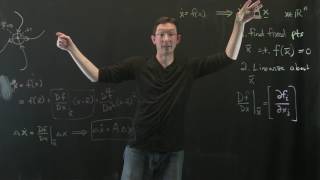
Linearizing Around a Fixed Point - Control Bootcamp
Explore linearization of nonlinear systems around fixed points, demonstrated with a simple pendulum example using both manual calculations and MATLAB implementation.
Seminar in the Analysis and Methods of PDE - Christopher K.R.T. Jones
Explore stability indices for nonlinear waves and patterns in PDEs, focusing on Evans Function and Maslov Index approaches, their geometric interpretations, and recent advancements in complex problem analysis.
Stability and Lifting Properties for C*-Algebras and Groups - Lecture 1
Explore stability and lifting properties in C*-algebras and groups, focusing on advanced mathematical concepts and their applications in operator theory.
Stability and Lifting Properties for C*-algebras and Groups - Lecture 3
Explore stability and lifting properties in C*-algebras and groups, delving into advanced mathematical concepts with expert insights from Tatiana Shulman.
Stability and Lifting Properties for C*-algebras and Groups - Lecture 2
Explore stability and lifting properties in C*-algebras and groups, delving into advanced mathematical concepts with expert insights from Tatiana Shulman.