
What Is a PID Controller?
Comprehensive introduction to PID controllers, explaining their components, functionality, and applications in control systems. Includes practical examples and code implementation guidance.
How to Tune a PID Controller for an Inverted Pendulum
Practical guide to manually tuning a PID controller for an inverted pendulum system, demonstrating Arduino-Python integration and step-by-step adjustment of Kp, Ki, and Kd parameters.
Topics at the Intersection of Control, Dynamics, and Learning from Data
Explore the convergence of control theory, dynamical systems, and data-driven learning in this insightful symposium talk by Eduardo Sontag from Northeastern University.
Linear Operator Theoretic Framework for Data-Driven Optimal Control
Explore a novel approach to data-driven optimal control using linear operator theory, presented by Umesh Vaidya from Clemson University at the Fourth Symposium on Machine Learning and Dynamical Systems.
State Estimation of Complex Systems
Explore state estimation techniques for complex systems, focusing on advanced methods and applications in dynamical systems and machine learning.
Operational Cybersecurity of Distributed Energy Resources Using Optimization, Control Theory, and ML
Explore cybersecurity challenges in distributed energy systems and learn techniques for detecting and mitigating cyber attacks using optimization, control theory, and machine learning.
Path Integral Control Theory
Explore path integral control theory, a powerful mathematical framework for optimal control in complex systems. Gain insights into its applications and mathematical foundations.
Feedback Design Principles for Efficient and Reliable Robot Learning
Exploring fusion of feedback control and reinforcement learning for efficient, reliable robot learning. Discusses reward shaping, co-design of controllers and algorithms, and future directions in robotics.
Linear Quadratic Control and Online Learning - 2019 ADSI Summer Workshop
Explore linear quadratic control and online learning with Yishay Mansour. Gain insights into algorithmic foundations of learning and control in this comprehensive workshop presentation.
An Online Learning Approach to Model Predictive Control - 2019 ADSI Summer Workshop
Explore online learning approaches to Model Predictive Control with Byron Boots, focusing on algorithmic foundations and innovative applications in learning and control systems.
Convex Optimization I - Fundamentals and Applications
Explore fundamental concepts and applications of convex optimization with Microsoft researcher Sebastien Bubeck in this comprehensive lecture on mathematical programming techniques.
Non-Asymptotic Analysis of a Classical System Identification Algorithm - 2019 ADSI Summer Workshop
Explore non-asymptotic analysis of classical system identification with Necmiye Ozay, delving into advanced algorithmic foundations for learning and control in this insightful conference presentation.
Making Decisions with Known Unknowns - Professor Eric Kerrigan's Inaugural Lecture
Explore decision-making under uncertainty, covering aerodynamics, electrical engineering, and energy systems. Learn optimization techniques for real-world problem-solving.
The Legacy of Rudolph Kalman - Systematic Approaches to Data-Driven Predictive Modeling
Explore Rudolph Kalman's groundbreaking work on data-driven mathematical modeling and its impact on fields like space control, weather prediction, and AI. Gain insights into optimization and iteration concepts.
Nonholonomic Systems with Inequality Constraints
Explore nonholonomic systems with inequality constraints, delving into advanced concepts and applications in control theory and robotics.
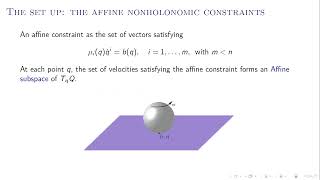
Virtual Affine Nonholonomic Constraints
Explore virtual affine nonholonomic constraints in mechanical systems, examining their mathematical foundations and practical applications in robotics and control theory.
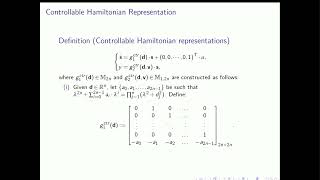
Expressiveness and Structure Preservation in Learning Port Hamiltonian Systems
Explore advanced techniques for learning Port Hamiltonian systems, focusing on expressiveness and structure preservation in dynamic modeling and control applications.
Course Introduction and Motivation to Phase Locked Loops - Part I
Explore Phase Locked Loops (PLLs), their fundamental concepts, and diverse applications in modern electronic systems. Gain insights into this crucial technology's importance and versatility.
Type-III Compensator Using Op Amp-RC Architecture
Learn to design and implement Type-III compensators using Op Amp-RC architecture for improved control system performance and stability in power electronics applications.
Safe Learning in Robotics
Explore safe learning algorithms for robots in complex environments. Discover data-efficient, online methods guaranteeing safety and adaptability for real-world applications in robotics and AI.
Control Principles for Robot Learning
Explore control principles for robot learning, focusing on motion synthesis, learning objectives, and real-time control algorithms. Gain insights from biology and robotics examples.