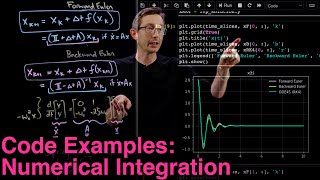
Numerical Integration of ODEs with Forward Euler and Backward Euler in Python and Matlab
Explore Forward and Backward Euler integration methods for ODEs using Python and Matlab. Compare stability, error, and implementation on a spring-mass-damper system with analytic solutions.
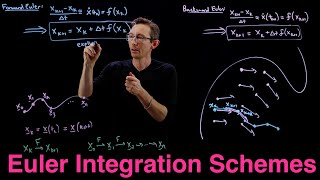
Deriving Forward Euler and Backward-Implicit Euler Integration Schemes for Differential Equations
Explore Forward and Backward Euler integration methods for ODEs, including derivations, error sources, and stability analysis. Gain insights into numerical integration techniques for solving differential equations.
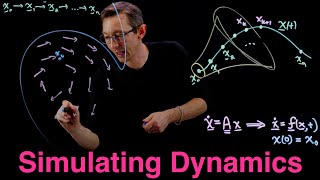
Numerical Simulation of Ordinary Differential Equations - Integrating ODEs
Explore numerical integration of ODEs to analyze nonlinear systems and generate trajectories. Learn techniques for solving complex dynamics where analytic methods fall short.
Linearizing Around a Fixed Point - Control Bootcamp
Explore linearization of nonlinear systems around fixed points, demonstrated with a simple pendulum example using both manual calculations and MATLAB implementation.
Gaussian B-Inequality: Stability and Equality Cases
Explore stability and equality cases in the Gaussian B-inequality, based on collaborative research with Livshyts, Rotem, and Volberg.
Classification, Reduction and Stability of Toric Principal Bundles
Explore toric principal bundles' classification, reduction, and stability in this mathematical lecture, delving into advanced concepts in algebraic geometry and group theory.
Factorization of the Calderón Problem Through the Born Approximation
Explore analytic techniques in dynamics and geometry, focusing on the Calderón problem and its factorization through the Born approximation.
Structure of Feigenbaum Henon Maps
Explore Feigenbaum Henon maps structure in dynamical systems with Mikhail Lyubich's conference talk, part of a broad meeting celebrating Marcelo Viana's 60th birthday at IMPA.
Multisymplectic Unscented Kalman Filter for Geometrically Exact Beams
Explore advanced filtering techniques for geometrically exact beam models using multisymplectic unscented Kalman filters in structural engineering applications.
Fast Probabilistic Inference for ODEs with ProbNumDiffEq.jl
Explore probabilistic ODE solvers with ProbNumDiffEq.jl. Learn Bayesian inference for numerical problems, implementation details, and future prospects in the Julia ecosystem.
Fluctuation Limits for Mean-Field Interacting Nonlinear Hawkes Processes
Explore fluctuation limits in mean-field interacting nonlinear Hawkes processes, delving into advanced mathematical concepts and their applications.
Stability and Asymptotic Behavior of Fronts in Bidomain Models
Explore stability and asymptotic behavior of fronts in bidomain models with Hiroshi Matano's in-depth analysis and insights.

Differential Equations: The Language of Change
Explore dynamical systems and differential equations through intuitive examples. Learn key concepts like state variables, phase portraits, and limit cycles to understand how systems change over time.
Creating the Controls - Rigging a Basic Robot in Maya - Part 3
Learn to rig a basic robot in Maya, focusing on creating controls for eyes, wheels, and body groups. Master essential techniques for character animation and control systems.
How to Rig a Character - Blender 3D Character Course
Learn character rigging in Blender 3D: Create a functional skeleton, set up controls, and prepare your 3D model for animation. Master essential techniques for bringing characters to life.
Create an Advanced Drifting Car Rig in 3ds Max - Part 2
Learn advanced techniques for creating a realistic drifting car rig in 3ds Max, enhancing your 3D animation skills and bringing dynamic vehicle movements to life.
Invariant Representation of Physical Stability in the Human Brain
Explore how the human brain represents physical stability, from infant intuition to neural computations, and its applications in robotics and computer vision.
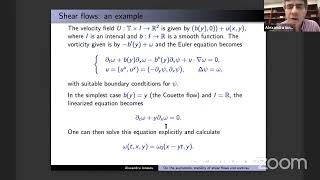
On the Global Stability of Shear Flows and Vortices
Explores recent findings on linear and nonlinear stability of shear flows and vortices in Euler equations, covering monotonic shear flows, point vortices, and smooth decreasing vortices.
Machine Learning for Scientific Discovery, with Examples in Fluid Mechanics
Explore machine learning for nonlinear dynamical systems modeling, focusing on the SINDy algorithm and its applications in fluid dynamics, with emphasis on interpretable and physics-respecting solutions.
Computational Principles of Sensorimotor Control - Lecture 1
Explore computational principles of sensorimotor control, including optimal feedback control, state estimation, motor learning, and Bayesian decision theory in human movement and robotics.
Capturing Turbulent Dynamics and Statistics in Experiments Using Exact Coherent States
Explore turbulent dynamics using Exact Coherent States, revealing coherent structures in experiments, forecasting turbulent evolution, and providing a geometric description of transient turbulence.