Autodiagnosis and the Dynamical Emergence Theory of Basic Consciousness
Explore the theory of basic consciousness, its emergence, and related concepts like energy landscapes and metastable states in this thought-provoking discussion on the nature of experience.
Effectual Topological Complexity
Explora la Complejidad Topológica Efectual, una nueva versión para G-Espacios. Aprende sus propiedades, relación con TC estándar y aplicación en superficies, especialmente en el toro.
Topological Complexity Using Arbitrary Covers
Explore topological complexity using arbitrary covers, focusing on sectional category, ANRs, and generalized concepts. Gain insights into advanced algebraic topology techniques and applications.
Musing About Robotic Football
Explore robotic football strategies, discussing modeling, non-fibrations, speed, sensing, and topological complexity in the context of navigating blockers to score.
Topological Complexity of Pure Graph Braid Groups
Explore topological complexity in graph braid groups, focusing on Farber's conjecture about ordered configuration spaces and its implications for topological robotics.
An Upper Bound on the Topological Complexity of Discriminantal Varieties
Explore upper bounds on topological complexity of discriminantal varieties, with applications to configuration spaces. Combines Morse theory, equivariant homotopy theory, and complex geometry.
Bedlewo- Topological Complexity and the Motion Planning Problem in Robotics
Explore topological complexity in robotics motion planning, its algebraic topology properties, recent developments, and research trends in this rich field.
Enrique Torres-Giese - Sequential Motion Planning Assisted by Group Actions
Sequential motion planning with group actions: exploring effectual and effective TC, orbital topological complexity, and their relationships. Calculations for actions on orientable surfaces and spheres included.
Steve Scheirer - Relative Topological Complexity and Configuration Spaces
Explore relative topological complexity and configuration spaces in this advanced algebraic topology talk, covering definitions, results, and applications.
Jamie Scott - Applications of Surgery to a Generalized Rudyak Conjecture
Exploring applications of surgery theory to Rudyak's conjecture, discussing generalizations to topological complexity, and examining cases for simply connected codomains.
Surfaces in 3-Manifolds and the Thurston Norm
Explore the Thurston norm in 3-manifold topology, its significance in measuring surface complexity, and its role in understanding modern topological breakthroughs.
Topological Complexity of Fibrations and Covering Maps
Explore topological complexity of fibrations and covering maps, examining their homotopy invariance and applications in robotics and mechanical device manipulation.
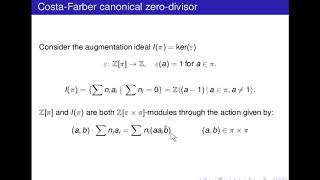
Bedlewo - Topological Complexity of the Klein Bottle
Explore the topological complexity of non-orientable surfaces, focusing on the Klein bottle and extending findings to surfaces of genus ≥2. Collaborative research insights shared.
Wanted- Topologists for Autonomous Robots Community
Exploring topological complexity in robotics: from path planning to task spaces. Insights into rigorous formulations for robotic autonomy, emphasizing environment topology and combinatorics in cooperative motion.
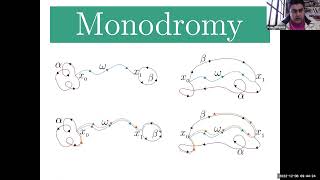
Symmetric and Symmetrized Topological Complexity of the Torus
Explore symmetric and symmetrized topological complexity of the torus, completing the description for closed surfaces using obstruction theory and explicit resolution of integers over full braid group.
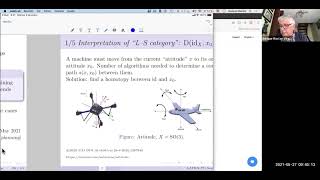
Homotopic Distance and Generalized Motion Planning
Explore homotopic distance between maps, unifying Lusternik-Schnirelmann category and topological complexity. Learn how Morse-Bott functions and navigation functions apply to generalized motion planning problems.
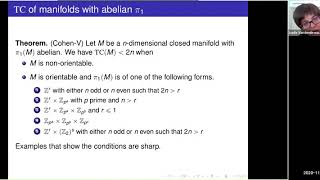
Topological Complexity for Manifolds with Abelian Fundamental Group
Explores conditions for nonmaximal topological complexity in manifolds with abelian fundamental groups, generalizing results on spaces with small fundamental groups and nonorientable surfaces.
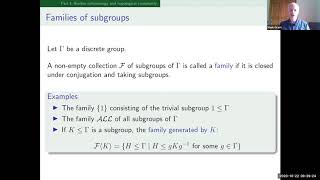
Bredon Cohomology and LS-Categorical Invariants
Explore Bredon cohomology's role in estimating topological complexity of aspherical spaces and its application to equivariant LS-category of groups with operators.
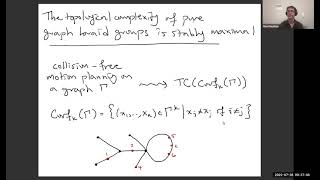
The Topological Complexity of Pure Graph Braid Groups Is Stably Maximal
Explore the topological complexity of configuration spaces in graphs, using group theoretic estimates for higher topological complexity instead of traditional cohomology approaches.
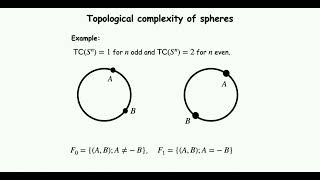
Michael Farber - Topological Complexity of Spherical Bundles
Explore parametrized motion planning algorithms and the topological complexity of sphere bundles, examining characteristic classes and specific examples in applied algebraic topology.
Higher Topological Complexity of Seifert Fibered Manifolds
Explore LS-category and topological complexity of Seifert fibered manifolds, examining lower bounds for higher TC using cohomology class weights and deriving TC_n ranges.