An Upper Bound on the Sequential Topological Complexity
Exploring upper bounds on sequential topological complexity in robot motion planning, with applications to lens spaces and improved dimensional upper bounds under group actions.
Bounds for the Higher Topological Complexity of Configuration Spaces
Explore bounds for higher topological complexities in unordered configuration spaces of trees and anchored configuration spaces of circles with two anchor points.
Effective Topological Complexity and Effective Lusternik-Schnirelmann Category
Exploring effective topological complexity and Lusternik-Schnirelmann category in motion planning, focusing on symmetries in configuration spaces and their impact on problem complexity.
Sequential Parametrized Topological Complexity of Sphere Bundles
Introduction to sequential parametrized motion planning and its application to sphere bundles, exploring algorithms that navigate systems through prescribed states while adapting to variable external conditions.
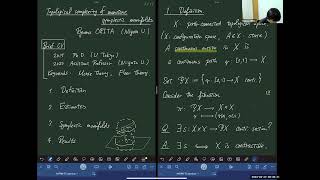
Topological Complexity of Monotone Symplectic Manifolds
Explore topological complexity in 4D spherically monotone manifolds, focusing on Kodaira dimension estimation and its implications for symplectic geometry.
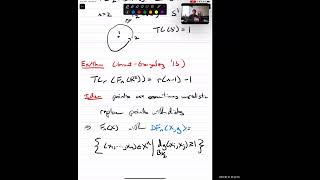
Disk Configuration Spaces and Topological Complexity
Exploring disk configuration spaces, their topology, and topological complexity, focusing on ordered configurations of unit-diameter disks in infinite strips and their geometric implications.
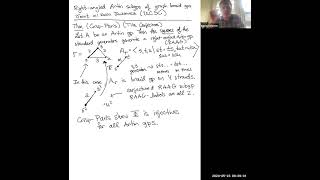
Right-Angled Artin Subgroups of Graph Braid Groups
Explore right-angled Artin subgroups in graph braid groups, examining recent conjectures and their applications to topological complexity in algebraic topology.
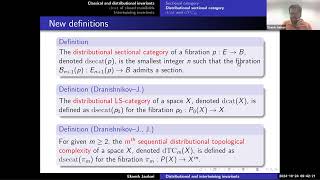
Distributional and Intertwining Invariants of Manifolds
Delve into advanced algebraic topology concepts, exploring distributional LS-category, sequential topological complexity, and intertwining invariants in manifolds, with applications to motion planning.
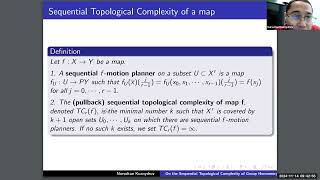
Sequential Topological Complexity of Group Homomorphisms
Delve into advanced algebraic topology concepts, exploring sequential topological complexity of maps and group homomorphisms through detailed mathematical analysis and computations.