An Intuition-Based Approach to Reinforcement Learning
Explore an intuition-based approach to reinforcement learning, covering key concepts like exploit vs. explore, Q-tables, and stochastic actions, with practical examples and applications.
Why AI is Harder Than We Think
Explore AI's challenges and misconceptions with Melanie Mitchell, delving into fallacies, overconfident predictions, and the complexities of intelligence. Gain insights on creating more robust, general, and adaptable AI systems.
Using Deep Learning for Perception in Autonomous Systems - A Perspective from Control Theory
Explore deep learning for perception in autonomous systems, focusing on efficient navigation using monocular RGB cameras in unknown environments. Control theory insights and practical lessons included.
Artificial Intelligence: Success, Limits, Myths and Threats - Lecture 1
Explore AI's successes, limitations, and societal impact. Delve into machine learning, neural networks, and the future of AI. Gain insights on scientific intelligence and ethical considerations.
Towards Assurance-Based Learning-Enabled Cyber-Physical Systems
Exploring formal verification, monitoring, and safety case formalization for assurance-based learning-enabled cyber-physical systems, focusing on autonomous vehicles and their complex components.
Bridging the Gap Between Safety and Real-Time Performance for Autonomous Vehicle Control
Explores a novel trajectory planning method for autonomous vehicles, balancing safety and real-time performance through offline computations and runtime optimization to ensure persistent feasibility.
Perception and Learning for Autonomous Driving - Part 1
Explore perception and learning for autonomous driving, covering sensor suites, deep neural networks, and object detection techniques in this comprehensive tutorial.
Physics Matters - In Artificial Intelligence - Natural and Artificial Cognition
Explore natural and artificial cognition, machine learning, and computer vision applications in healthcare, research, and autonomous vehicles with Professor Kalle Åström.
The Role of Conventions in Adaptive Human-AI Interaction
Explores partner modeling in multi-agent coordination, focusing on representation learning, conventions, and strategies for reducing non-stationarity in decentralized systems.

Building the Elegoo Smart Robot Car - Arduino Based Robotics Project
Step-by-step guide to assembling an Arduino-based Elegoo Smart Robot Car, covering component overview, assembly process, and initial testing of this versatile educational robotics project.
Next-Generation Deep-Learning Accelerators: From Hardware to System - tinyML Summit 2022
Explore next-gen deep learning accelerators, focusing on system-level challenges and opportunities in design, integration, and scheduling for future AI hardware advancements.
Learning Robust Policies for Self-Driving
Explore robust policies for self-driving vehicles, covering TransFuser for sensor fusion, PlanT for learned planning, and KING for identifying critical scenarios in autonomous driving.
Driving with Attention
Explore innovative sensor fusion techniques for autonomous driving, focusing on TransFuser and NEAT models that leverage attention mechanisms to improve perception and decision-making in complex traffic scenarios.
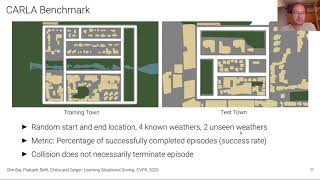
Learning Robust Driving Policies
Explore robust driving policies for autonomous vehicles, covering situational reasoning strategies and addressing covariate shift in imitation learning to improve generalization and safety in diverse conditions.
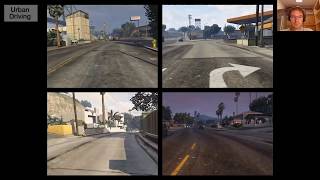
Label Efficient Visual Abstractions for Autonomous Driving
Explore efficient visual abstractions for autonomous driving, analyzing segmentation-based modalities and their impact on driving performance in CARLA simulator. Gain insights on label-efficient approaches.
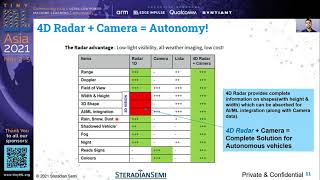
Imaging Radars - Learning for Enhanced Vision in Modern Radar Systems
Explore imaging radars and machine learning for enhanced object classification in traffic enforcement and autonomous driving applications using millimeter-wave technology.
Convolutional Neural Networks
Explore convolutional neural networks for computer vision, covering feature extraction, convolution operations, and applications like object detection and self-driving cars.
Perception and Collaboration in Robotics - Session 18
Explore cutting-edge research on perception and collaboration in robotics and AI, focusing on advancements in sensing, decision-making, and multi-agent systems.
Use Dmabuf to Streamline Sensor Data Handling in Automotive Systems - Lecture
Streamlining sensor data handling in self-driving vehicles using Dmabuf, exploring efficient memory management and zero-copy data pipelines for modern automotive systems.
Self-Driving Car Simulation 5 - Traffic Ouroboros
Explore the concept of traffic ouroboros in a self-driving car simulation, testing autonomous vehicles in a challenging circular traffic scenario.
Self Driving Car Simulation 3 - Collision Avoidance
Learn to implement collision avoidance in self-driving car simulations using Unity, enhancing vehicle perception and safety features.