Autonomous Driving - AI's Biggest Endeavor, James Peng of Pony.ai
Explore autonomous driving's potential impact, challenges, and innovations with Pony.ai's James Peng. Gain insights into sensors, AI, and the future of transportation.
Stanford Seminar - Autonomous Driving, Are We There Yet? - Technology, Business, Legal Considerations
Exploring autonomous driving's technological, business, and legal challenges. Discusses paradigm shifts in personal mobility, industry transformation, and steps needed to realize this revolutionary vision for transportation.

The Era of Artificial Intelligence
Explore the four waves of AI, its global economic impact, and potential challenges in this insightful talk by Kai-Fu Lee on the future of artificial intelligence and its pervasive influence.
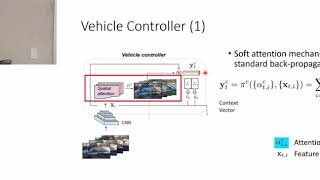
Textual Explanation for Self-Driving Vehicles
Explore self-driving vehicle technology through an explainable driving model, focusing on network architecture, preprocessing, and evaluation of vehicle control and explanation generation.
Learning Steering for Parallel Autonomy
Explores end-to-end learning for parallel autonomy in self-driving cars, focusing on handling ambiguity, uncertainty estimation, and decision-making capabilities beyond reactionary control.
Optimizing Robot Action Around and For People
Explore strategies for optimizing robot actions in human environments, focusing on prediction, interaction, and shared utility to enhance human-robot collaboration and safety.
Software Defines the Vehicle - Why Customers and Developers Will Love Cars Even More
Explore how software is revolutionizing the automotive industry, enhancing user experiences and creating exciting opportunities for developers in vehicle technology.
From State Space Control to Intelligent Machines - A Five-Decade Journey in Mechanical Systems Control
Explore a five-decade journey in mechanical systems control, from state space theory to intelligent industrial robots and autonomous driving. Gain insights from Masayoshi Tomizuka's research at UC Berkeley.
Zenseact Open Dataset for Advancing Autonomous Driving
Explore the Zenseact Open Dataset's role in advancing autonomous driving technology. Learn about its creation, features, and applications in ongoing research projects.
Get Ready for Vehicle Digital Transformation
Explore vehicle digital transformation with insights on emerging technologies, industry trends, and future automotive innovations.

Programming Autonomous Self-Driving Cars with Carla and Python
Explore autonomous driving simulation using Carla and Python. Learn to create virtual environments, control vehicles, and implement self-driving logic with open-source tools and APIs.
Reliable Object Detection and Identification in Adverse Conditions
Explore radar-based perception systems for autonomous vehicles, focusing on reliable object detection in adverse weather conditions and multi-sensor fusion techniques for enhanced safety.
Challenges in Using LLM-as-a-Judge for Production Evaluations
Explore key techniques and challenges in using LLMs as evaluation tools for AI applications, with insights on improving RAG-based systems and implementing production-grade assessments.
Implementing Automated Lane-Keeping Systems (ALKS) Models in SUMO Traffic Simulator
Explore the implementation requirements of Automated Lane-Keeping Systems (ALKS) in SUMO traffic simulation, focusing on UNECE R157 regulations and practical development steps.
Improving Autonomous Driving Platforms with Zenoh-Flow Data Flow System
Discover how Zenoh-Flow structures complex applications into computing units, demonstrated through an Autonomous Driving platform implementation with focus on deployment automation and business logic development.
Empower Autonomous Driving with Cloud Native Serverless Technologies
Explore how cloud-native serverless technologies empower autonomous driving, addressing challenges in data archiving, resource management, and architecture flexibility for complex use cases and numerous modules.
Introduction to ADAS and Autonomous Driving
Explore ADAS and autonomous driving fundamentals, hardware components, functions, computing requirements, software elements, and their impact on road safety and transportation.

Reinforcement Learning - Full Course Using Python
Comprehensive introduction to reinforcement learning using Python, covering fundamentals, custom environments, and practical projects like Atari games and autonomous driving.
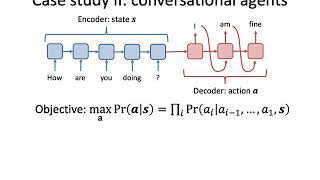
Imitation Learning
Explore imitation learning techniques, from behavioral cloning to generative adversarial methods, with applications in autonomous driving and conversational agents.
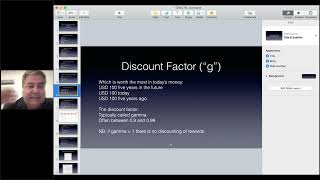
An Intuition-Based Approach to Reinforcement Learning
Explore an intuition-based approach to reinforcement learning, covering key concepts like exploit vs. explore, Q-tables, and stochastic actions, with practical examples and applications.
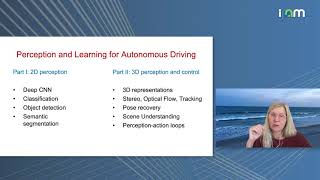
Perception and Learning for Autonomous Driving - Part 1
Explore perception and learning for autonomous driving, covering sensor suites, deep neural networks, and object detection techniques in this comprehensive tutorial.