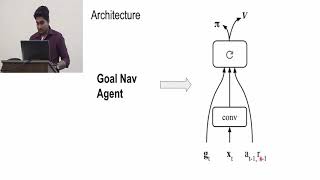
Learning to Navigate in Cities Without a Map
Explore reinforcement learning techniques for autonomous navigation in unmapped urban environments, focusing on value functions, courier tasks, and multi-site experiments.
El punto ciego en el camino de la vida - Fractales y perseverancia en robótica espacial
Andrés Mora explora cómo los fractales y la perseverancia se aplican en robótica y navegación espacial, utilizando su experiencia en la NASA para ilustrar el manejo de desafíos en la vida y la tecnología.
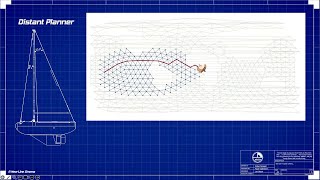
Building a Robot to Sail Across the Atlantic - Lessons from Autonomous Sailboat Development
Erfahre, wie autonome Segelboote entwickelt werden: Von Rumpf und Segelplan über Elektronik bis zur Programmierung. Lerne aus den Erfahrungen des Sailingteam Darmstadt beim Bau von Robotern für die Atlantiküberquerung.
WebTalk on PICs for LIDAR Systems
Explore coherent FMCW LiDAR technology for autonomous navigation, featuring insights on silicon photonics, advanced optics, and the Innovation Support Fund application process.
Autonomous Navigation of Turtlebot Using ROS - ROS Tutorials for Beginners
Learn to autonomously navigate a Turtlebot using ROS by creating an auto_nav package and writing custom code, without relying on RVIZ. Practical implementation of navigation concepts for mobile robots.
Using a Lidar for Robot Navigation in a Room
Explore LASER rangefinder integration for autonomous robot navigation, including Linux requirements and control software. Learn techniques for 3D mapping and obstacle avoidance on embedded Linux platforms.
The CubeRover for Lunar Mobility as a Service
Explore CubeRover: an innovative, ultra-light lunar rover for diverse payloads. Learn about its modular design, scalability, and potential to revolutionize lunar exploration and commercial space ventures.
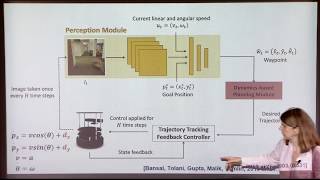
Using Deep Learning for Perception in Autonomous Systems - A Perspective from Control Theory
Explore deep learning for perception in autonomous systems, focusing on efficient navigation using monocular RGB cameras in unknown environments. Control theory insights and practical lessons included.
Learning to Fly
Explore the journey of teaching drones to race autonomously, from initial coding to developing a complete system for understanding and navigating complex environments safely.
Autonomous Exploration Robotics with a Raspberry Pi
Explore autonomous robotics using Raspberry Pi to build Nyx, a self-sustaining exploration robot capable of long nautical journeys. Learn about electronics, telemetry, and software for DIY robotics projects.
AI for Autonomous Mobile Robots - Computer Vision and Navigation Systems
Explore how AI and computer vision enable autonomous mobile robots to navigate safely alongside humans in logistics, focusing on deep learning, mapping, and advanced navigation algorithms.
Robotics Training - Measuring Distance to Obstacle Using the HC-SR04
Learn to measure obstacle distance using HC-SR04 ultrasonic sensor for robotics projects. Practical coding and hardware setup included for implementing distance measurement in robotic applications.

Perceive Before Learning to Plan or Act - Multitask Perception Systems for Autonomous Agents
Explore advanced perception systems for autonomous agents in dynamic environments. Covers multi-object tracking, human motion forecasting, and social interaction analysis for safe navigation and interaction.