Lagrange's Equations from D’Alembert’s Principle - Worked Examples
Explore D'Alembert's Principle and Lagrange's Equations through worked examples, including baton sliding, cart-pendulum system, and spring-mass system. Learn to formulate equations of motion for multiparticle systems.
D’Alembert’s Principle of Virtual Work - Active Forces and Workless Constraint Forces
Explore D'Alembert's Principle of Virtual Work, analyzing active forces and workless constraint forces in analytical dynamics. Gain insights into nonholonomic constraints and multiparticle systems.
Lagrange's Equations Introduction - Generalized Coordinates, Constraints, Degrees of Freedom
Comprehensive introduction to Lagrangian mechanics, covering generalized coordinates, constraints, and degrees of freedom. Explores holonomic and nonholonomic constraints, with examples including the intriguing shopping cart instability.
Rigid Body Dynamics - Stability About Principal Axes - Qualitative Analysis of Spinning Objects
Explore rigid body dynamics, stability of principal axes, and qualitative analysis of spinning objects. Understand the tennis racket theorem and intermediate axis instability through demonstrations and intuitive explanations.
Rigid Body Kinematic Differential Equation for Euler Angles and Rotation Matrix
Comprehensive exploration of rigid body kinematics, focusing on Euler angles, rotation matrices, and differential equations. Covers singularities, alternatives, and applications in free rigid body motion analysis.
Rotational Dynamics About an Arbitrary Reference Point - Planar Rigid Body Motion - Car Jump Example
Explore rotational dynamics of rigid bodies using arbitrary reference points, with applications to car jumps and planar motion. Covers angular momentum, Euler's equations, and moment of inertia concepts.
Newton-Euler Equations for a Rigid Body - Center of Mass & Inertia Tensor Calculation Worked Example
Comprehensive exploration of rigid body dynamics, covering mass distribution, center of mass calculation, Newton-Euler equations, and rotational motion, with practical examples and mathematical formulations.
Tetherball, Angular Momentum, and Central Forces - Indiana Jones's Whip, Snake Wrapping Around a Tree
Explore tetherball dynamics, angular momentum, and central forces through real-world examples like Indiana Jones's whip and tree snakes. Learn to solve nonlinear ODEs and analyze spring-mass systems in the plane.
Planar Kinematics & Dynamics of a Particle
Explore planar kinematics and particle dynamics, covering projectile motion, pendulums, polar coordinates, and the transport equation for rotating frames. Gain insights into 2D motion analysis.
Normal Forms for Vector Fields
Introduction to normal forms for vector fields, focusing on simplifying nonlinear terms and determining topological equivalence. Covers theory, examples, and applications in dynamical systems analysis.
Center Manifolds for Hamiltonian Systems and PDEs - Lorenz System Bifurcation, Part 2
Explore center manifolds in Hamiltonian systems and PDEs, including Lorenz system bifurcation, unstable directions, and applications to flame front evolution and celestial mechanics.
Center Manifold Theory - Computing Center Manifolds
Explore center manifold theory for dynamical systems, focusing on computing and approximating center manifolds. Learn to analyze stability and dynamics near equilibrium points using Taylor series expansions and tangency conditions.
Stability of Periodic Orbits - Floquet Theory - Stable and Unstable Invariant Manifolds
Explore stability of periodic orbits using Floquet theory. Learn about monodromy matrices, Floquet multipliers, and invariant manifolds in Hamiltonian systems. Understand the foundations of chaos in dynamical systems.
Periodic Systems and Periodic Motion - Parametric Resonance Tongues of Instability, Mathieu Equation
Explore periodic systems, parametric resonance, and the Mathieu equation. Learn about resonance tongues, stability analysis, and the fascinating Kapitza pendulum phenomenon in nonlinear dynamics.
Hamiltonian Normal Forms, Lie Series Method for Transformations - Infinite-Dimensional Hamiltonians
Explore Hamiltonian normal forms, Lie series transformations, and infinite-dimensional systems. Learn to simplify complex dynamics and analyze PDEs like shallow water equations.
Poisson Brackets, Non-Canonical Hamiltonian Systems and Euler's Rigid Body Equations
Explore Poisson brackets, non-canonical Hamiltonian systems, and Euler's rigid body equations in this advanced dynamics lecture. Gain insights into abstract algebra, Lie algebra, and their applications in physics and mechanics.
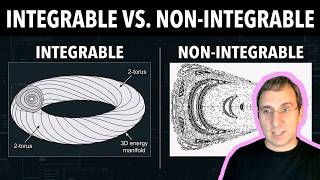
Integrable and Non-Integrable Hamiltonian Systems - KAM Tori - Poincare Sections - Poisson Brackets
Explore integrable and non-integrable Hamiltonian systems, KAM theory, Poincaré sections, and Poisson brackets in this advanced dynamics lecture, offering insights into complex nonlinear systems and their behavior.
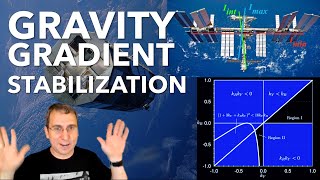
Gravity Gradient - Stability Conditions, Frequencies, Torque Equilibrium Angle, Space Station
Explore gravity gradient effects on spacecraft stability, including Euler equations, pitch stability, torque equilibrium angles, and applications to the International Space Station.
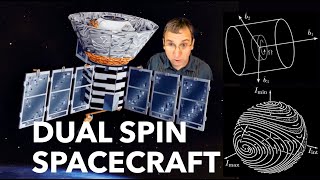
Dual-Spin Spacecraft - Instability of Intermediate and Minimum Principal Axes for Free Rigid Bodies
Explore dual-spin spacecraft stabilization, intermediate axis instability, and long-term minimum axis instability. Learn about historical space missions and passive attitude stability techniques.
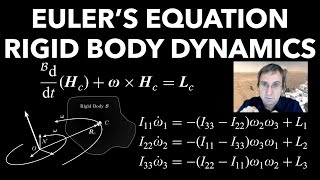
Euler's Equations of Rigid Body Dynamics Derived - Qualitative Analysis - Build Rigid Body Intuition
Comprehensive exploration of Euler's equations for rigid body dynamics, covering derivation, analysis, and practical applications through various examples like spinning tops and fidget spinners.
Center of Mass and Moment of Inertia Matrix - Example Calculations
Example calculations for center of mass and moment of inertia matrix in space vehicle dynamics. Covers planar rigid bodies, composite shapes, and practical applications using integrals and common approximation methods.