Open Source Robotics: Current Landscape and Future Directions
Explore the current landscape, challenges, and future of open source robotics. Learn inspiring stories and how to get started in this rapidly growing field accelerated by Ubuntu-based projects.
ROS on Fedora IoT - Containerized Deployment for Robotics
Streamline ROS deployment on Fedora IoT using bootable containers. Explore containerized approach, easy image building, and reliable upgrade mechanisms for robotics development.

Virtual-Physical Environment Manipulation System Based on ROS - Python and Three.js Integration
Explore ROS-based virtual-physical environment manipulation using Python, Three.js, and WebRTC. Learn architecture, tools, and implementation for interactive 3D visualizations and robotic control.
Introduction to the Robot Operating System - ROS Middleware
Learn about the Robot Operating System (ROS) middleware, its installation, core components, and practical application in creating a small mobile robotic platform. Gain insights from an industry expert.

GStreamer and ROS - A Tale of Two Messaging Frameworks
Exploring GStreamer and ROS: Comparing messaging frameworks for multimedia and robotics, their design patterns, and potential integration for flexible, high-performance systems.
Robot Operating System - How Open Source Software and Linux is Powering the Next Generation of Robotics
Explore ROS 2's role in advancing robotics through open-source software and Linux, revolutionizing the development of next-generation robotic systems.
Integrating ROS into EdgeX: Building a Unified Edge Computing System
Explore integrating ROS into EdgeX for unified edge computing solutions, covering architecture, device nodes, machine learning, lightweight Linux, and edge computing cluster vision.
Bringing Ubuntu's Infrastructure to Your Robot
Discover how to leverage Ubuntu Core and Snaps for secure, efficient robotics development and deployment, unlocking reliable update infrastructure for your devices.
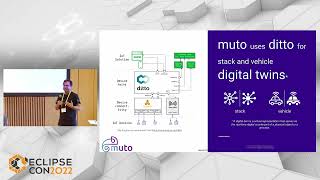
Eclipse Muto - Adaptive Framework for Model-Driven ROS Software Stacks
Discover how Eclipse Muto enables dynamic composition and management of ROS-based software stacks for autonomous vehicles through adaptive frameworks and IoT integration with Eclipse Ditto.
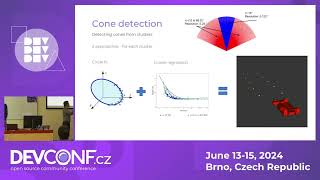
Design and Development of Autonomous Racecar
Explore autonomous racecar development: perception, localization, mapping, path planning, and vehicle control. Gain insights into creating self-driving vehicles using advanced technologies.