Robotic Simulator - Adding 2D/3D Objects into the Project
Learn to import and integrate 2D/3D objects from various sources into Unity for robotic simulation. Covers formats, drag-and-drop, mesh rendering, animation, and asset store imports.

Stepper Motors and Arduino - The Ultimate Guide
Comprehensive guide on controlling stepper motors with Arduino, covering NEMA17 motors, various drivers, programming, and practical applications. Includes code examples and hardware comparisons.
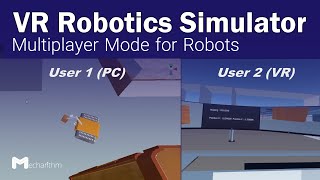
VR Robotics Simulator - Multiplayer Mode for Robots - VR Tutorials for Beginners
Implement multiplayer mode for robots in VR, sharing positions and orientations, and enabling voice chat between users in Unity using Photon network SDK.
Robotic Simulator - How to Save-Load the Values and Show Them as a Table
Learn to save, load, and display data in a robotic simulator, enhancing the main menu and other simulator components. Explore practical applications for managing essential information in Unity-based simulations.
Robotic Simulator - Creating an Advanced UGV Robot in Unity with C#
Simulate complex robot actions like picking up and dropping objects in Unity. Learn to create advanced UGV robot behaviors using C# programming and Unity's physics engine.
Robotic Simulator - Triggers
Explore Unity triggers for scenario design in robotic simulators. Learn practical applications and essential techniques to enhance your simulation capabilities.
Robotic Simulator - Creating a Simple UGV Robot in Unity with C#
Design and implement a UGV robot in Unity with C#, featuring manual and automatic movement capabilities. Learn to create and control autonomous ground vehicles in a simulated environment.
Robotic Simulator- C# Scripting in Unity - Beginner
Learn to create a simple moving car in Unity with multiple camera views, implementing forward, backward, left, and right movements using C# scripting.
Robotic Simulator - Physics in Unity
Explore Unity's physics components for robotic simulation, focusing on Box Collider, Rigid Body, and Hanging Joint to enhance realism in your virtual robot designs.
Object Detection Using OpenCV - Augmented Reality Using OpenCV
Learn object detection with OpenCV for augmented reality applications. Recognize objects as triggers for AR functions, enhancing your robotics and mechatronics skills.
The Hand Prosthesis That Learns from the User
Explore machine learning in hand prostheses that adapt to users, enhancing control and functionality. Learn about challenges, solutions, and future developments in this innovative field.