A Review of Compression Methods for Deep Convolutional Neural Networks
Explore compression techniques for Convolutional Neural Networks, including pruning, distillation, and quantization, to optimize deployment on tinyML devices without compromising accuracy.
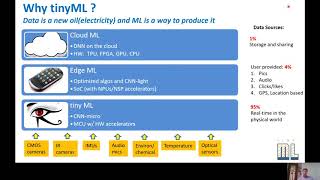
Recent Progress on TinyML Technologies and Always-On Machine Opportunities
Explore recent advancements in tinyML technologies, their implementation, and potential applications across various industries, with a focus on always-on machine learning for voice, vision, and sensing.
How to Train and Deploy TinyML Models for Three Common Sensor Types
Learn to train and deploy tinyML models for sensor, audio, and vision data using Edge Impulse. Explore workflows, best practices, and optimization techniques for embedded machine learning applications.
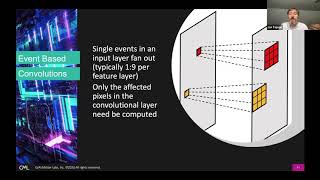
Saving 95% of Your Edge Power with Sparsity to Enable TinyML
Explore sparsity techniques to drastically reduce power consumption in edge ML, enabling real-time processing for tinyML applications with the innovative GrAI Core architecture.
TinyML Talks - Dr. Dominic Binks- TinyML Doesn’t Need Big Data, It Needs Great Data
Explore challenges and solutions in obtaining quality audio data for tinyML sound recognition, focusing on data sources, collection methods, labeling strategies, and performance evaluation.
Train One Network and Specialize It for Efficient Deployment
Explore efficient neural network deployment across diverse devices using the Once-for-All network approach, which enables quick specialization without retraining and outperforms state-of-the-art methods on edge devices.
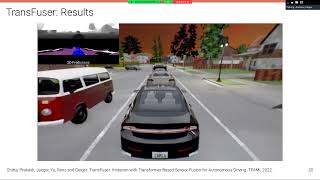
Learning Robust Policies for Self-Driving
Explore robust policies for self-driving vehicles, covering TransFuser for sensor fusion, PlanT for learned planning, and KING for identifying critical scenarios in autonomous driving.
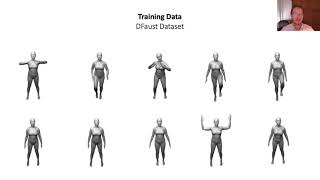
Towards Animatable Human Avatars
Explore cutting-edge techniques for creating animatable human avatars using neural implicit shapes and meta-learning approaches, with applications in computer vision and graphics.
Towards Nonlinear Disentanglement in Natural Data with Temporal Sparse Coding
Explore unsupervised disentanglement of factors in natural videos using SlowVAE. Learn about temporal sparse coding, identifiability proof, and performance on benchmark datasets including new natural dynamics benchmarks.
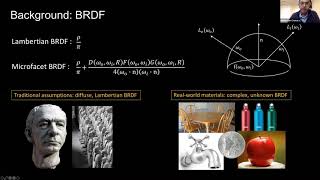
Physically-Motivated Learning of Shape, Material and Lighting in Complex Scenes
Explores physically-motivated learning for shape, material, and lighting recovery in complex scenes using differentiable rendering layers and parsimonious representations, enabling augmented reality applications with single or few images.
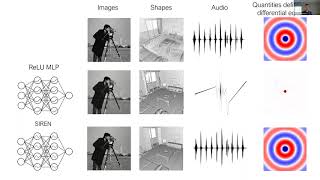
Implicit Neural Scene Representations
Explore implicit neural representations for complex signals, enabling 3D reconstruction from single images and fast inference through gradient-based meta-learning, with applications in scene understanding and semantic segmentation.
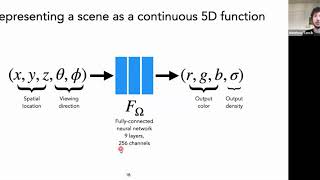
Neural Radiance Fields for View Synthesis
Explore neural radiance fields for view synthesis, combining coordinate-based neural representations with volumetric rendering to achieve state-of-the-art results in synthesizing novel views of complex scenes.
Unmasking the Inductive Biases of Unsupervised Object Representations for Video Sequences
Explore unsupervised object-centric learning approaches for video sequences, comparing perceptual abilities in detection, segmentation, and tracking using a benchmark dataset of procedurally generated videos.
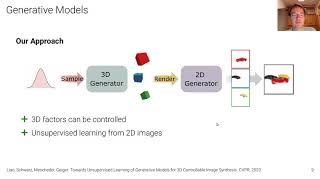
Towards Unsupervised Learning of Generative Models for 3D Controllable Image Synthesis
Explores unsupervised learning for 3D-controllable image synthesis, disentangling latent factors like viewpoint and object pose from raw images to create novel, consistent scenes.
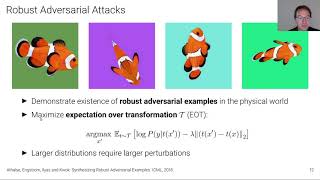
Attacking Optical Flow
Explores adversarial patch attacks on optical flow networks, revealing vulnerabilities in deep learning-based motion estimation crucial for autonomous driving safety.
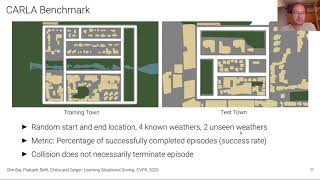
Learning Robust Driving Policies
Explore robust driving policies for autonomous vehicles, covering situational reasoning strategies and addressing covariate shift in imitation learning to improve generalization and safety in diverse conditions.
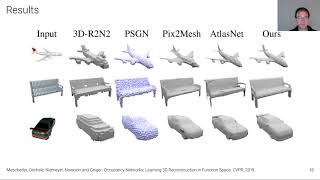
Learning 3D Reconstruction in Function Space - Long Version
Explore neural implicit 3D representations for geometry, texture, and motion reconstruction. Learn innovative techniques for modeling complex 3D shapes using continuous function spaces and 2D supervision.
Label Efficient Visual Abstractions for Autonomous Driving
Explore efficient visual abstractions for autonomous driving, analyzing segmentation-based modalities and their impact on driving performance in CARLA simulator. Gain insights on label-efficient approaches.
Stefan Roth: Robust Scene Analysis
Explore robust scene analysis techniques, focusing on optical flow estimation, motion segmentation, and uncertainty in computer vision tasks. Learn about challenges, objectives, and innovative approaches.
Making Our Models Robust to Changing Visual Environments
Explore techniques for making machine learning models robust to changing visual environments, covering domain adaptation, adversarial optimization, and continuous learning strategies.
DALI 2018 - Andreas Geiger: How to Satisfy the Thirst for Data
Explore innovative approaches to address data scarcity in computer vision, including specialized architectures, soft constraints, self-supervision, and label transfer techniques.