Toward Generalizable Embodied AI for Machine Autonomy
Explore recent advancements in machine autonomy, focusing on generalizable embodied AI through sequential decision-making, simulation environments, and human-AI collaboration.

Machine Learning - What Is Easy, Medium, and Hard?
Explore the landscape of machine learning through case studies, examining easy, medium, and hard challenges while considering future possibilities and potential pitfalls.
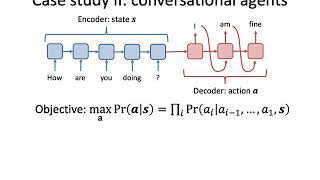
Imitation Learning
Explore imitation learning techniques, from behavioral cloning to generative adversarial methods, with applications in autonomous driving and conversational agents.
Alternatives to Reinforcement Learning for Real-World Problems
Explore alternatives to Reinforcement Learning for real-world problems, focusing on Contextual Bandits and Imitation Learning. Learn their applications, limitations, and how they differ from full RL.
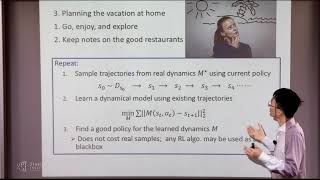
Practical Model-Based Algorithms for Reinforcement Learning and Imitation Learning
Explore efficient model-based algorithms for reinforcement and imitation learning, addressing challenges in learning dynamics and uncertainty, with practical examples and evaluations.
Interpretable Machine Learning via Program Synthesis - IPAM at UCLA
Explore interpretable machine learning through program synthesis, focusing on control policies and RNA splice prediction. Learn novel approaches for creating custom, problem-specific model families.
Pieter Abbeel on Research Directions - Full Stack Deep Learning - November 2019
Explore cutting-edge deep learning methods with Professor Pieter Abbeel, covering few-shot learning, reinforcement learning, imitation learning, domain randomization, architecture search, and unsupervised learning.
Generalization and Robustness in Offline Reinforcement Learning
Explore offline reinforcement learning for safety-critical applications, covering generalization, robustness, and imitation learning in large-scale settings with rich function approximation.
Reinforcement Learning - Emma Brunskill - Stanford University
Explore reinforcement learning fundamentals, applications, and challenges with Stanford's Emma Brunskill, covering AI planning, machine learning, and decision-making processes.
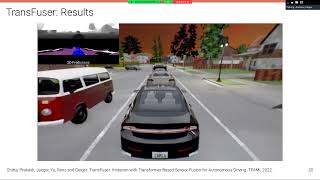
Learning Robust Policies for Self-Driving
Explore robust policies for self-driving vehicles, covering TransFuser for sensor fusion, PlanT for learned planning, and KING for identifying critical scenarios in autonomous driving.
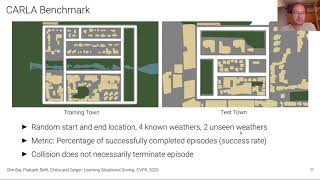
Learning Robust Driving Policies
Explore robust driving policies for autonomous vehicles, covering situational reasoning strategies and addressing covariate shift in imitation learning to improve generalization and safety in diverse conditions.

Geometry Aware Imitation Learning in Robotics
Explores geometry-aware imitation learning for robots, enabling precise movement planning and skill acquisition from demonstrations. Discusses handling non-Euclidean data using differential geometry tools.
Successfully Use Deep Reinforcement Learning in Testing and NPC Development
Explore deep reinforcement learning for game testing and NPC development, focusing on effective approaches, cost mitigation, and real-world applications in Unity projects.
Democratize Machine Learning - ML-Agents Explained
Explore Unity ML-Agents: an open-source toolkit bridging Unity and machine learning. Learn about reinforcement and imitation learning techniques for innovative game development and AI applications.
Human - AI Interaction Loop Training as a New Approach for Interactive Learning
Explore a novel approach combining imitation learning with reinforcement learning methods, leveraging human feedback to enhance AI decision-making in complex environments.
Generalizable Autonomy for Robot Manipulation
Explore generalizable autonomy in robot manipulation through imitation learning, visuo-motor policies, and reinforcement learning techniques. Discover innovative approaches for achieving adaptable and efficient robotic systems.
Tracing the Path to Self-adapting AI Agents
Discover how Trace, a groundbreaking AutoDiff-like framework, enables end-to-end training of AI workflows using general feedback, revolutionizing how AI agents learn and adapt through Python-based implementation.
Multi-Agent AI Systems: From Imitation Learning to Markov Game Theory
Explore advanced game theory concepts in multi-agent AI systems, covering investment strategies, cybersecurity applications, and the evolution from reinforcement learning to imitation learning frameworks.
Beyond Rules and Rewards: From Pixels to Adaptive Policies Through Imitation, Reinforcement, and Multimodal Learning
Explore advanced robotic learning methodologies, from imitation-based training to multimodal systems, focusing on adaptive policies and vision-language models for enhanced real-world robot interactions.
Data-Driven Fine Manipulation in Robotics - 2024 Winter Robotics Colloquium
Data-driven approaches for fine manipulation in robotics, enhancing precision and adaptability. Research focuses on empowering general-purpose hardware systems to automate delicate tasks using imitation learning and reinforcement learning techniques.
Towards Long-Horizon Robot Task Learning
Explore cutting-edge research on complex robot task learning, including simulation environments, hierarchical decomposition, and skill chaining for long-horizon tasks in robotics and AI.