Simple Turtlebot Simulation in ROS - ROS Tutorials for Beginners
Learn to simulate Turtlebot in ROS, explore mobile robot kinematics, and gain hands-on experience with ROS tools and packages for robotics development and visualization.
How to Create a ROS Workspace and a ROS Package - ROS 101 - ROS Tutorials for Beginners
Learn to create ROS workspaces and packages, use ROSlaunch, and work with rqt visualization tool. Covers Python3 installation, package management, and essential ROS concepts for beginners.
Chasing a Tennis Ball with ROS
Learn to use ROS and OpenCV for ball detection and tracking, enabling a robot to follow a tennis ball in both simulated and real-world environments.

Making Robot Navigation Easy with Nav2 and ROS
Learn to implement robot navigation using Nav2 and ROS, covering setup, simulation in Gazebo, real-world application, AMCL integration, and practical tips for efficient implementation.

Easy SLAM with ROS Using Slam Toolbox
Learn to implement SLAM for mobile robots using ROS and slam_toolbox. Covers setup, mapping, localization, and practical application on real robots. Ideal for beginners in robotics and autonomous navigation.
Control Your ROS Robot From Your Phone
Learn advanced ROS robot control techniques, including web servers, Foxglove Studio, RViz Teleop, and stamped twists. Explore simulation improvements and alternative teleop tools for enhanced mobile robotics.

Easy Wireless Control for Your Homemade Robot
Learn to control homemade robots wirelessly using game controllers. Explore Linux and ROS integration, joystick-to-command conversion, and real-time feedback visualization in RViz.
Solving the Problem Every Robot Has - With ROS2_Control
Overview of ros2_control implementation in Gazebo simulation, covering hardware interfaces, controllers, and practical setup for robotic systems.
How to Get Your Robot to See in 3D - Depth Cameras in ROS
Learn to integrate depth cameras with ROS for 3D vision in robotics. Covers simulation in Gazebo, real camera setup (OAK-D Lite), and point cloud visualization for enhanced robot perception.

How to Use Cameras in ROS - Sim Camera and Pi Camera
Comprehensive guide on integrating cameras in ROS, covering theory, simulation, image viewing, compression, and real camera connections for robotics applications.

How Do We Add LIDAR to a ROS Robot?
Learn to integrate LIDAR into ROS robots, covering URDF modifications, Gazebo simulation, and real hardware integration. Gain practical insights for enhancing robot perception capabilities.

The Ultimate Guide to Using Motors in Robotics - Including ROS, Raspberry Pi
Comprehensive guide on integrating motors in robotics, covering hardware connections, control methods, and ROS implementation using Raspberry Pi. Includes practical demonstrations and code examples.
Driving Your Virtual Robot
Learn to simulate and control a virtual robot in Gazebo, covering spawning, launch files, control plugins, teleop, friction adjustment, RViz visualization, and obstacle course creation.
Simulating Robots with Gazebo and ROS - Getting Ready to Build Robots with ROS
Learn to simulate robots using Gazebo and ROS, covering installation, robot spawning, joint control, virtual world creation, and sensor integration. Gain practical skills for advanced robotics development.
How Do We Describe a Robot? With URDF! - Getting Ready to Build Robots with ROS
Learn to describe robots using URDF (Unified Robot Description Format) in ROS. Covers links, joints, syntax, xacro for simplification, and a practical example.
Fusion 360 Tutorial from Punished Props
Learn Fusion 360 through a hands-on tutorial, modeling various parts for a Wayne's World Licorice Dispenser. Perfect for beginners, this step-by-step guide makes 3D modeling accessible and fun.
Replacing Heel Caps - Nicks Handmade Boots
Learn the process of replacing heel caps on handmade boots, from cleaning and removing old stacks to attaching new ones, sanding, staining, and polishing for a professional finish.
SPACE Webinar Series - Image Enhancement and Noise Removal Techniques
Explore cutting-edge signal processing techniques for image restoration, noise removal, and low-light enhancement in this comprehensive webinar series.
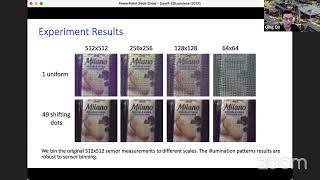
Computational Imaging and Mask-Based Techniques - SPACE West Webinar
Explore computational imaging techniques, including mask-based imaging and lensless imaging, with Prof. Salman Asif. Learn about depth reconstruction, simulation results, and practical applications.
Elastography Techniques in Medical Imaging - From Palpation to Subharmonic Imaging
Explore advanced ultrasound techniques and elastography methods with Prof. Doyley, covering palpation, harmonic imaging, and stress analysis for medical applications.
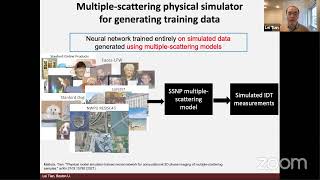
Computational Microscopy Using LED Array for 3D Phase Imaging - Prof. Lei Tian
Explore advanced computational microscopy techniques using LED arrays for multimodal imaging, 3D phase reconstruction, and deep learning applications in high-resolution biological sample analysis.