
CHIP $9 Computer
Explore the discontinued CHIP single board computer, its features, and setup process. Comparison with modern alternatives like Raspberry Pi Zero W included.
Distributed Cloud for Telcos Innovation - Oracle Solutions for 5G and Industry Vertical Strategy
Explore Oracle's distributed cloud solutions for telcos, enabling 5G innovation, efficient network operations, and digital service delivery through advanced infrastructure and edge computing.
These Robots Change the Future of Work
Explore futuristic robots revolutionizing industries through force amplification, teleoperation, and surveillance. Discover Sarcos Robotics' innovative solutions and gain insights into the evolving workforce and robotics career opportunities.
Robotic Simulator - Streaming the Variables in the Network
Learn to stream essential variables between users in a multiplayer robotic simulator, enabling data sharing and enhancing collaborative robotics projects in Unity.
Screws - A Geometric Description of Twists in Robotics - Fundamentals of Robotics
Explore screw theory in robotics, covering twist interpretation, matrix representation, frame changes, and exponential coordinates for rigid body motions. Includes practical examples and configurations.
Velocities in Robotics - Angular Velocities & Twists - Fundamentals of Robotics
Explore angular velocities and twists in robotics, covering concepts, demonstrations, and practical examples like robot arm motion and merry-go-round spinning. Enhance your understanding of robot motion fundamentals.
Homogeneous Transformation Matrices in Robotics - Fundamentals of Robotics
Explore homogeneous transformation matrices in robotics, covering SE(3) and SE(2) groups, properties, uses, and frame transformations with practical examples and applications.
Unit Quaternions in Robotics - Great Demos - Fundamentals of Robotics
Explore unit quaternions in robotics: definition, conversion, applications, and demonstrations using UR5e robot and enDAQ sensors. Gain insights into this singularity-free orientation representation method.
Exponential Coordinates in Robotics - Fundamentals of Robotics
Explore exponential coordinates in robotics, covering interpretations, linear differential equations, cross products, matrix logarithms, and practical demonstrations with a two-degree-of-freedom robot wrist.
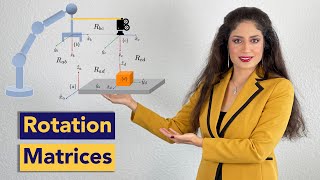
Rotation Matrices in Robotics - Fundamentals of Robotics
Explore rotation matrices in robotics: properties, uses, and applications. Learn implicit orientation representation, frame changes, and rotations with practical demonstrations for robotic systems.
Soft Robotic Grippers Using Kirigami Shells - When Art Meets Robotics
Explore innovative soft robotic grippers using Kirigami shells, capable of handling diverse objects from sand grains to water bottles. Learn about design, applications, and the intersection of art and robotics.
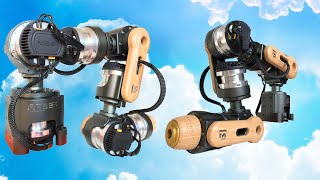
The Kinda Affordable 7DoF Robot Arm - Amber B1
Explore the affordable 7-axis Amber B1 robot arm, featuring impressive 3kg payload, high precision, and versatile applications. Learn about its capabilities and potential impact on robotics.
Why the Brushless Controllers Are Awesome for Robotics
Explore the benefits of brushless controllers in robotics, including easy Arduino programming and practical applications, despite imperfections in performance.
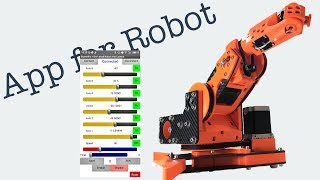
Robot Arm Programmed and Controlled with Smartphone - Bluetooth
Control and program a robotic arm using a smartphone app with Bluetooth connectivity, no coding required. Includes step-by-step guide and demonstration of the DIY project.

Forward Kinematics in Robotics Using Screw Theory - Matlab Code & Great Demos
Learn forward kinematics using screw theory and product of exponentials formula. Explore applications on planar, UR5e, and SCARA robots with MATLAB demonstrations and practical examples.
Autonomous Navigation of Turtlebot Using ROS - ROS Tutorials for Beginners
Learn to autonomously navigate a Turtlebot using ROS by creating an auto_nav package and writing custom code, without relying on RVIZ. Practical implementation of navigation concepts for mobile robots.
Navigation, Path Planning & Control Using AMCL Package - ROS Tutorials for Beginners
Learn to implement robot navigation, path planning, and control using ROS's amcl package. Practice localizing a robot during motion in Gazebo and setting autonomous movement between points in RVIZ.
Localization, Mapping & SLAM Using Gmapping Package - ROS Tutorials for Beginners
Explore localization, mapping, and SLAM in robotics. Learn to use Turtlebot3's gmapping package in Gazebo for creating global maps with LIDAR, combining theory and hands-on practice.
Turtlebot3 Gazebo Tutorial - ROS Tutorials for Beginners
Learn to simulate Turtlebot3 in Gazebo using ROS. Download the package, launch the simulator, and control the robot in a virtual environment. Gain hands-on experience with ROS and robotics simulation.
ROS Parameter Server and ROS Bags - ROS Tutorials for Beginners
Learn to manipulate the ROS Parameter Server and work with ROS Bags for data recording, playback, and analysis. Gain practical skills in managing parameters and handling robot data efficiently.
ROS Services - Server and Client - ROS 101 - ROS Tutorials for Beginners
Learn to create ROS service clients and servers, exploring the differences between client-server and publisher-subscriber architectures in this hands-on tutorial with practical examples and troubleshooting tips.