Jetson AI Labs - Introduction to Duckietown and Autonomous Robotics
Explore Duckietown's innovative robotics platform with NVIDIA Jetson, featuring insights on MOOCs, hardware, and real-world applications in this informative AMA-style livestream.
Challenging Path to Creating Autonomous and Controllable Microrobots
Exploring breakthroughs in microrobotics: autonomous crawling, controllable flying, and ultrafast SMA-driven robots. Innovations in power, actuation, and control push boundaries of insect-scale robotics towards true artificial insects.
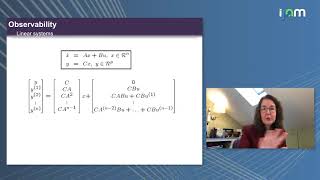
Analytical and Empirical Tools for Nonlinear Network Observability in Autonomous Systems
Explore nonlinear network observability in autonomous systems, covering analytical and empirical tools for sensor selection, network analysis, and applications in engineering and biology.
Safe Learning in Robotics
Explore safe learning in robotics, covering reachable sets, collision avoidance, fast planning, and human-robot interaction. Gain insights into cutting-edge techniques for autonomous systems.
Safety-Critical Autonomous Systems - What is Possible? What is Required?
Explore the design, challenges, and potential of safety-critical autonomous systems in aerospace, transportation, and consumer applications, focusing on verification and formal methods.
Certifiable Outlier-Robust Geometric Perception - Robots that See through the Clutter with Confidence
Explore cutting-edge algorithms for robust geometric perception in robotics, enhancing safety and reliability in autonomous systems across various applications.
Better Ways to Measure and Move - Joint Optimization of Agent's Physical Design and Computational Reasoning
Explore joint optimization of physical design and computational reasoning for intelligent agents, enhancing sensor networks, legged robots, and soft robotics through machine learning techniques.
Privacy, Trust and the Future of Cybersecurity
Explore privacy, trust, and future tech challenges with cryptography expert Bruce Schneier. Delve into encryption, IoT risks, data breaches, and policy implications in our increasingly connected world.
Sample-Based Learning Model Predictive Control
Explores learning predictive control for autonomous systems, focusing on sample-based LMPC for constrained uncertain linear systems. Discusses safe set design, value function, and data-driven approximations, with applications in autonomous cars and solar…
Perception and Manipulation in Robotics - Session 14
Explore cutting-edge advancements in robotic perception and manipulation techniques, focusing on innovative approaches to enhance machine vision and dexterity in various applications.
Embodiment in Artificial Intelligence - Session 15
Explore advanced concepts of embodiment in AI and robotics, delving into the integration of physical form and cognitive processes for enhanced machine intelligence.
The Future of Cyber-Autonomy
Exploring autonomous cybersecurity systems like Mayhem, their potential to revolutionize software security, and implications for future defense strategies against machine-speed attacks.
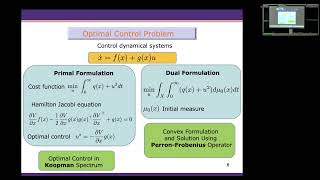
Linear Operator Theoretic Framework for Data-Driven Optimal Control
Explore a novel approach to data-driven optimal control using linear operator theory, presented by Umesh Vaidya from Clemson University at the Fourth Symposium on Machine Learning and Dynamical Systems.
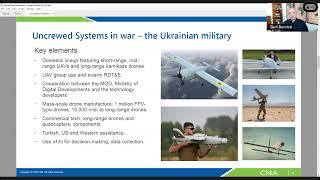
Update on the Use of Uncrewed and Autonomous Systems in the Ukraine War
Explore the latest developments in uncrewed and autonomous systems deployed in the Ukraine conflict, examining their strategic impact and technological advancements.
Robot Scientist - Exploring Artificial Intelligence in Research
Explore cutting-edge research in robotics and artificial intelligence with insights from a leading expert in the field.
Hierarchy, Abstractions and Geometry in Robotics - Spring 2021 Robotics Colloquium
Explore advanced robotics concepts, focusing on abstract reasoning and joint semantic-physical representations for improved planning and decision-making in complex environments.
Next-Generation Robot Perception: Hierarchical Representations, Certifiable Algorithms, and Self-Supervised Learning
Exploring next-gen robot perception: hierarchical representations, certifiable algorithms, and self-supervised learning for enhanced spatial understanding and robust estimation in robotics.
Interactive Imitation Learning - Planning Alongside Humans
Explore interactive imitation learning for robots to adapt to human preferences, focusing on challenges beyond dataset collection and enabling seamless human-robot collaboration in real-world scenarios.
Acceptance over Ignorance - How to Embrace Uncertainty in Robotic Manipulation
Exploring approaches to embrace uncertainty in robotic manipulation, including scaffolding, object-centric planning, and deformable object control, to enhance robustness and adaptability in dynamic environments.
Bio-inspired Drones for Sustainable Societal Good
Explore the future of bio-inspired flying robots and their potential to improve lives and protect the environment through autonomous tasks and intelligent design.
Physics-Assisted Multi-Robot Exploration
Explore cutting-edge techniques for multi-robot systems using physics-assisted approaches to enhance exploration and coordination in complex environments.