Hardware in Space - The Kernel at the Edge of the Universe
Explore the evolution of space-bound hardware, from core memory to ARM SoCs and real-time Linux. Learn about commodity hardware in space exploration and confidential computing's role in securing data beyond Earth.
Configure Zephyr: Kconfigs and Devicetree in Simple Words
Demystifying Zephyr's Kconfigs and Devicetree for RTOS engineers. Learn how these tools simplify development, with practical examples and comparisons to familiar concepts.
IoTivity-Constrained: IoT for Tiny Devices
Explore IoTivity-Constrained's architecture and features for implementing OCF IoT standards on resource-limited devices, including integration with real-time operating systems and adaptation for Zephyr RTOS.
Building Scalable Platforms - Lessons from Embedded Systems to Finance
Explore universal patterns for building top-performing platforms across industries. Gain insights on creating inspiring engineering environments that unleash creativity and innovation.

Zephyr Project - RTOS Start-up and Initialization Flow
Explore the RTOS startup and initialization process in Zephyr, covering early boot, kernel APIs, drivers, and static threads for embedded systems developers.
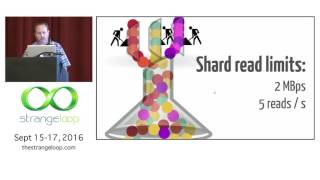
Distributed Commit Log - Application Techniques for Transaction Processing
Explore techniques for leveraging distributed commit logs in transaction processing, including handling duplicates, sharding, exceptions, and debugging in real-time systems.
A Zephyr User Story
Explore the decision-making process for RTOS selection and implementation in IoT startups, focusing on Zephyr's features, board support, and subsystems for industrial applications.
Developing Open-Source Software RTOS with Functional Safety in Mind
Explore integrating open-source RTOS development with functional safety standards, focusing on Zephyr project's innovative approach using public tools to meet safety requirements.

Linux and Zephyr - Talking to Each Other in the Same SoC
Explore inter-core communication between Linux and Zephyr on hybrid multiprocessors using RPMsg, with practical demonstrations and insights for real-time applications.
Zephyr OS Memory Protection
Explore MPU-based memory protection in Zephyr RTOS, covering security domains, permission management, object allocation, system calls, and IPC mechanisms for embedded systems.
Reinforcement Learning in Action - Creating Arena Battle AI for Blade & Soul
Discover how NCSOFT created pro-level AI agents for arena battles in Blade & Soul using reinforcement learning, addressing complexity and real-time response challenges.
Machine Learning for Optimal Matchmaking
Explore TrueMatch, a machine learning approach for optimizing matchmaking in real-time, balancing player skill, wait times, and other metrics for improved gaming experiences.
Optimizing Embedded Hard Real-Time Code in C++
Techniques for optimizing C++ in embedded hard real-time systems, improving performance without hardware changes. Explores efficient coding practices and C++ facilities for faster execution and better maintainability.
LiveMLP - ML Platform for Assisting Contact Center Agents in Real-Time
Explore a real-time ML platform designed to assist contact center agents, addressing challenges in throughput, latency, and fault tolerance while improving customer support efficiency.
How Go is Making Us Faster
Explore how Go programming language enhances web performance, enabling real-time auctions and ad serving at 2.3 million queries per second. Learn about Go's features, tools, and benefits for high-performance systems.
Modern Event-driven Architecture - Adopting Data in Motion
Explore event-driven architectures and data in motion, covering Kafka, event streams, and principles for effective implementation. Learn to leverage real-time data for business success.
The O-RAN SC RIC - RAN Intelligent Controller
Explore O-RAN SC RIC architecture, protocols, and implementation status. Learn about xApp API, northbound/southbound interfaces, and upcoming changes in RAN Intelligent Controller.
Zephyr RTOS Juicy Features Using Simple Evaluation Boards and Robots
Explore Zephyr RTOS features using evaluation boards and robots. Learn to write code, build applications, and implement device drivers for embedded systems and robotics projects.
Pocket6 - A 6DoF Controller Based on a Simple Smartphone Application
Innovative smartphone app for 6DoF input, rivaling expensive controllers. Offers high accuracy, accessibility, and versatility for 2D/3D object manipulation without external trackers or spatial limitations.
To RTOS, or Not RTOS - That is the Question
Explore the pros and cons of RTOSes vs. bare metal approaches for embedded computing and IoT, comparing popular open-source options and os-less frameworks to help choose the right approach for your project.
A Month Off - Migrating a Robot Controller from the Proprietary INtime RTOS to Linux
Explore the journey of migrating a robot controller from INtime RTOS to Linux, including technical challenges, realtime requirements, and implementation strategies for system objects and processes.