Secure & Democratize the Data in Your Customer's Brownfield Devices
Secure legacy devices, add cybersecurity, and integrate operational data into modern IIoT infrastructure using edge programmable industrial controllers for digital transformation initiatives.
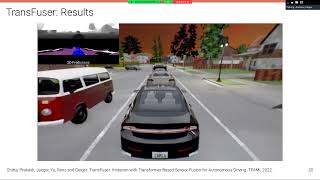
Learning Robust Policies for Self-Driving
Explore robust policies for self-driving vehicles, covering TransFuser for sensor fusion, PlanT for learned planning, and KING for identifying critical scenarios in autonomous driving.
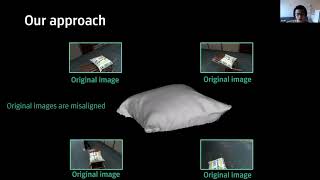
Appearance Acquisition for Digital 3D Content Creation
Explore advanced techniques for digital 3D content creation, including texture recovery, mesh reconstruction, and volumetric representation, using machine learning and computer vision approaches.
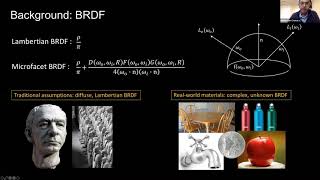
Physically-Motivated Learning of Shape, Material and Lighting in Complex Scenes
Explores physically-motivated learning for shape, material, and lighting recovery in complex scenes using differentiable rendering layers and parsimonious representations, enabling augmented reality applications with single or few images.
DALI 2018 - Andreas Geiger: How to Satisfy the Thirst for Data
Explore innovative approaches to address data scarcity in computer vision, including specialized architectures, soft constraints, self-supervision, and label transfer techniques.
Raspberry Pi Pico & VL53L0X for MicroPython
Learn to integrate the VL53L0X Time of Flight sensor with Raspberry Pi Pico using MicroPython. Includes setup, library usage, and practical demonstrations for robotics applications.
Using the Raspberry Pi Pico, PCA9685 and MicroPython for Robotics
Learn to control multiple servos using Raspberry Pi Pico, PCA9685, and MicroPython for robotics projects. Covers I2C communication, troubleshooting, and practical implementation with a robot example.
Raspberry Pi Pico and Range Finder
Learn to use HC-SR04 Range Finder with Raspberry Pi Pico, including voltage adjustment, wiring, and MicroPython programming. Hands-on demos and practical examples included.
Raspberry Pi Pico, OpenCat and MicroPython - Servo Easing
Learn to create smooth servo motion using easing algorithms in MicroPython on Raspberry Pi Pico. Practical examples and real-world applications for robotics projects, including OpenCat implementation.
Raspberry Pi Pico, OpenCat and MicroPython
Learn to build an OpenCat robot using Raspberry Pi Pico and MicroPython. Covers modeling, motion, inverse kinematics, balancing, and servo upgrades. Includes live coding and demonstrations.
Raspberry Pi Pico for Robotics
Explore the powerful, affordable Raspberry Pi Pico microcontroller for robotics projects. Learn its features, capabilities, and how to program it using MicroPython, comparing it to other popular boards.
Face Detection with OpenCV
Learn face detection using OpenCV and Python on Raspberry Pi Zero. Explore object detection, AI, neural networks, and computer vision fundamentals. Practical implementation and insights provided.
Supercharge Your Vision AI Business with NVIDIA Metropolis
Discover how NVIDIA Metropolis can enhance your Vision AI business through improved performance, streamlined deployments, enterprise readiness, and access to GPU infrastructure and business support.
DirectX 11 Debugging with Parallel Nsight 2.1
Learn advanced DirectX 11 debugging techniques using Parallel Nsight 2.1, covering pipeline setup, shader authoring, and new features for efficient game and engine development.
OpenGL and CUDA-Based Tessellation
Explore advanced tessellation techniques using CUDA to overcome OpenGL limitations, enabling higher-order surfaces, custom UV coordinates, and trimming curves for improved visual quality in graphics rendering.
Tools for Mobile Photography and Computer Vision
Explore computational photography and computer vision for mobile devices, covering NVIDIA's research, hardware developments, and software tools like OpenCV and FCam for innovative mobile applications.
Visual AI in Milliwatts - A Grand Challenge and Massive Opportunity
Explore visual AI's potential in low-power devices, discussing challenges, opportunities, and applications in security cameras and beyond. Learn about deep learning, processors, and algorithms driving this technology.
tinyMLPerf: Benchmarking Ultra-low Power Machine Learning Systems
Explore benchmarking for ultra-low power ML systems, focusing on tinyMLPerf's methodology, tasks, and ecosystem impact. Learn about quantization and community-driven efforts in this emerging field.
Energy-efficient On-device Processing for Next-generation Endpoint ML - tinyML Summit 2020
Explore energy-efficient on-device processing for endpoint machine learning, focusing on Arm's Cortex-M55 CPU and Ethos-U55 NPU for next-generation AI applications.
Resource Efficient Machine Learning in a Few KBs of RAM - tinyML Summit 2020
Explore resource-efficient machine learning techniques for IoT devices with limited RAM, focusing on Microsoft's EdgeML library and algorithms like ProtoNN and FastRNN for edge computing.
Build Your Own Web Server Using a Raspberry Pi Pico W Using Phew
Learn to create a web server on Raspberry Pi Pico W using Phew library. Covers installation, WiFi connection, logging, templates, Bootstrap, and forms for interactive project websites.