My Leadership Story - Climbing the Ladder of Success
Inspiring journey of a young leader's rise to success, highlighting key skills and experiences that shaped his entrepreneurial and philanthropic endeavors.
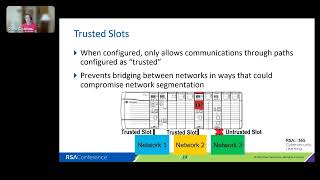
Beyond the Firewall - Ensuring OT Application Security
Explore OT application security principles, including IAM, secure development environments, secure coding for PLCs, and change detection strategies to enhance your operational technology security posture.
Data Assimilation - Kalman Filter - Lecture 7
Explore Kalman Filter in data assimilation for weather and climate models. Learn theoretical foundations and practical applications of this crucial mathematical approach.

Bluetooth Classic and BLE with ESP32 - Tutorial and Examples
Explore Bluetooth Classic and BLE with ESP32, covering device discovery, serial communication, and server-client interactions for IoT and mobile applications.

How Three-Phase Transformers Work and Their Importance
Comprehensive explanation of 3-phase transformers, their functionality, applications, and configurations. Covers voltage outputs, wye-delta connections, and transformer types used in power distribution systems.
High-Altitude Balloons - A Cost-Effective Alternative to Satellites for Earth Observation
Exploring high-altitude balloons as a cost-effective, versatile alternative to satellites for Earth observation, offering applications in vegetation monitoring, disaster response, and infrastructure surveillance.
Equity Considerations in Energy System Decarbonization - Session W24
Experts discuss equity in energy decarbonization, covering built environment, residential natural gas phase-out, justice metrics for research, and modeling equitable energy systems.
Moving Business Toward Human-Focused Impact - Industry 5.0 Strategy
Explore Industry 5.0's balanced approach to value creation, emphasizing human and natural capital alongside financial capital for sustainable, resilient business practices.
Spectrumize - Spectrum-efficient Satellite Networks for IoT
Innovative satellite network system for IoT devices, leveraging Doppler shift for improved packet detection and decoding in low-signal environments, with 3x better performance.
Open-Source Margo Initiative - Tackling Interoperability Challenges in Industrial Automation
Explore the Margo Initiative's approach to solving interoperability issues in industrial automation, focusing on orchestration at scale for edge applications and devices.
Policy Learning in Spatial Action Spaces for Robotic Manipulation
Explore innovative approaches to robotic policy learning in spatial action spaces for complex manipulation tasks, addressing challenges and evaluating solutions in simulated and physical environments.
Scaling Probabilistically Safe Learning to Robotics
Explores advancements in safe robot learning, focusing on imitation learning theory, scalable reward inference, and efficient policy evaluation to enable real-world deployment with safety guarantees.
Formal Synthesis for Robots - Leveraging Formal Methods in Robotic Design
Explore how formal methods and synthesis techniques can design, explain, and guarantee robot behavior, with examples of modular robots, swarms, and human-robot interaction.
Robot Learning From Few Demonstrations by Exploiting Data Structure and Geometry
Explore robot learning from limited demonstrations, leveraging data structure and geometry. Discover optimal control strategies and intuitive interfaces for efficient skill acquisition in human-robot interaction.
Hierarchy, Abstractions and Geometry in Robotics - Spring 2021 Robotics Colloquium
Explore advanced robotics concepts, focusing on abstract reasoning and joint semantic-physical representations for improved planning and decision-making in complex environments.
Structuring Manipulation Tasks for More Efficient Learning
Exploring modular approaches to teach robots versatile manipulation skills for unstructured environments, focusing on object-centric solutions, context adaptation, and material-based interactions.
Feedback Design Principles for Efficient and Reliable Robot Learning
Exploring fusion of feedback control and reinforcement learning for efficient, reliable robot learning. Discusses reward shaping, co-design of controllers and algorithms, and future directions in robotics.
Next-Generation Robot Perception: Hierarchical Representations, Certifiable Algorithms, and Self-Supervised Learning
Exploring next-gen robot perception: hierarchical representations, certifiable algorithms, and self-supervised learning for enhanced spatial understanding and robust estimation in robotics.
Stability and Learning in Strategic Queueing Systems
Explore stability and learning in strategic queueing systems with Éva Tardos. Discover how selfish behavior affects packet routing and server capacity in this insightful seminar on optimization and data analysis.
Towards $1 Robots
Explore the future of accessible robotics through innovative design, fabrication, and control methods. Learn how low-cost robots can revolutionize work, education, and play for everyone worldwide.
Constraints and Planning for Forceful Robotic Manipulation
Explore algorithms for robotic manipulation tasks requiring force and motion planning. Learn about constraints, task planning, and strategies for complex multi-stage operations like twisting nuts or using tools.