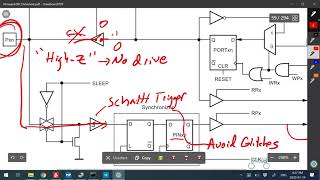
Introduction to GPIO with ATMega328P
Learn to program GPIO ports on ATMega328P microcontrollers using the Arduino Nano board. Covers port registers, bit masking, and practical examples for beginners and enthusiasts.
Scope Introduction - Probe Usage, Function Generator, Power Supply
Learn oscilloscope basics, probe settings, function generators, and power supplies. Hands-on demos cover timebase, triggering, and output settings for effective electronic measurements and testing.
Complete PCB Hand Assembly - FPGA in BGA Package + Reflow
Step-by-step guide to PCB hand assembly, including stencil alignment, component placement, and reflow soldering. Covers techniques for handling BGA and TQFP packages, using a vacuum tool, and operating a reflow oven.
Using the ADC
Learn to use Analog-Digital Converters (ADCs) effectively, covering architectures, quantization, resolution, and practical applications like metal detectors. Gain hands-on experience with ADC implementation and optimization.
Sensors
Explore sensor technologies, echo location, timers, and practical applications in robotics, including whiskers and bump sensors for enhanced navigation and interaction.
PLIP- Partial Reconfiguration of Spartan 6 FPGA
Learn to implement partial reconfiguration on Spartan 6 FPGAs using practical examples and Python scripts. Covers setup, FPGA Editor, output blocks, and DCM configurations.
Firmware Insider- Bluetooth Randomness is Mostly Random
Explore Bluetooth randomness, RNG variants, and security implications in firmware. Insights on PRNG, cloud data, MITM attacks, and recent patches for cryptographic enthusiasts.
LadderLeak
Explore ECDSA and Schnorr signatures, focusing on randomness vulnerabilities and side-channel attacks. Learn about new attack records and countermeasures in cryptographic implementations.
Training and Deploying AI for Industrial Robotics - Unite Now 2020
Explore AI training for industrial robotics using Unity, featuring domain randomization and insights on shaping the future of robotics from industry experts.
Sparse Fourier Transform Algorithm for Real-Time Applications
Explore real-time applications of Sparse Fourier Transform, including spectrum sensing and wireless networks, with algorithms for efficient signal processing and sparse recovery.
Predicting Intersection Signal Timing
Explore signal control parameters, queueing theory, and dynamic programming for optimizing intersection traffic flow and reducing fuel consumption.
Safe Learning in Robotics
Explore safe learning in robotics, covering reachable sets, collision avoidance, fast planning, and human-robot interaction. Gain insights into cutting-edge techniques for autonomous systems.
A Few Challenge Problems from Robotics
Explore challenging robotics problems, including backflips, models, perception, and optimization. Gain insights into reinforcement learning, state estimation, and physics-based approaches for advanced robotic systems.
Safety-Critical Autonomous Systems - What is Possible? What is Required?
Explore the design, challenges, and potential of safety-critical autonomous systems in aerospace, transportation, and consumer applications, focusing on verification and formal methods.
Feedback Control Theory - Architectures and Tools for Real-Time Decision Making II
Explore advanced control systems, design patterns, and optimization techniques for real-time decision making in complex systems. Learn about PID control, robustness, and temporal logic.
Emerging Trends & Applications in Communication Networks
Explore cutting-edge networking trends with experts discussing crypto, fake news, privacy, and social networks, offering insights into the future of communication technology.

Dynamic Robot Manipulation - Learned Optimization, Deformable Materials, and the Cloud
Explore dynamic robot manipulation through integrated planning, deep learning, and cloud computing for high-speed, reliable motions in unstructured environments.
Perceptual Robot Learning - David Held, CMU
Explore innovative approaches to robot perception and planning for manipulating diverse objects, enhancing capabilities in cloth handling, articulated objects, and transparent materials.
Learning Robot Policies from Imperfect Teachers - Taylor Kessler Faulkner, UT Austin
Explore algorithms for robots learning from imperfect human teachers, addressing inattention and inaccurate information to enhance interactive Reinforcement Learning and improve human-robot teaching interactions.
Certifiable Outlier-Robust Geometric Perception - Robots that See through the Clutter with Confidence
Explore cutting-edge algorithms for robust geometric perception in robotics, enhancing safety and reliability in autonomous systems across various applications.
Towards Generalization of Precise Robot Skills - Accurate Pick-and-Place of Novel Objects
Explore precise robotic generalization for pick-and-place tasks using simulation-learned models. Discover how visuo-tactile sensing enables accurate object manipulation and placement with sub-millimeter precision for novel items.