Controllability - Control Bootcamp
Explore linear system controllability through intuitive examples and the controllability matrix rank test. Learn key concepts for understanding and analyzing system control.
Tame Phenomena Over the Real Field - Lecture 6
Explore control theory concepts including flows, log spirals, limit cycles, and restricted analytic functions in this advanced graduate-level lecture on tame phenomena.
Trajectory Types Near L1, L2, and L3 in the Three Body Problem - Theory and MATLAB Examples
Explore trajectory types near Lagrange points in the three-body problem. Learn analytical solutions, MATLAB simulations, and applications to Earth-Moon and Sun-Jupiter systems. Gain insights into orbital dynamics and space mission design.
Simultaneous Control of Ensembles of Dynamical Systems
Control strategies for managing multiple dynamic systems simultaneously, focusing on mathematical approaches and applications in various fields.
Tame Control Theory - Lecture 5
Explore advanced concepts in tame control theory, focusing on phenomena over real fields. Delve into graduate-level mathematical analysis and applications.
Tame Phenomena Over the Real Field - Graduate Course Lecture 1
Explore fundamental concepts of tame control theory, focusing on real field applications and advanced mathematical principles in this graduate-level lecture.
Transport in Reservoir Computing
Explore the intersection of machine learning and dynamical systems, focusing on transport phenomena in reservoir computing and its applications in data analysis and prediction.
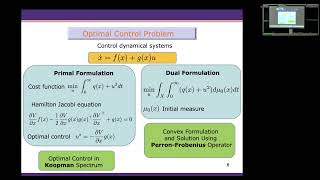
Linear Operator Theoretic Framework for Data-Driven Optimal Control
Explore a novel approach to data-driven optimal control using linear operator theory, presented by Umesh Vaidya from Clemson University at the Fourth Symposium on Machine Learning and Dynamical Systems.
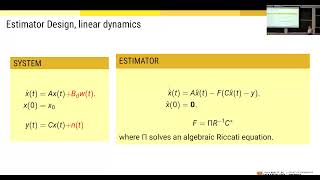
State Estimation of Complex Systems
Explore state estimation techniques for complex systems, focusing on advanced methods and applications in dynamical systems and machine learning.
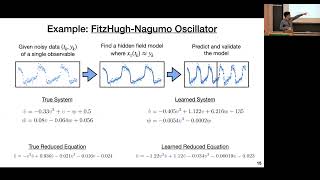
Discovering Dynamics and Parameters of Nonlinear Systems from Partial Observations
Explore techniques for uncovering nonlinear system dynamics and parameters using incomplete data, enhancing understanding of complex systems and their behavior.
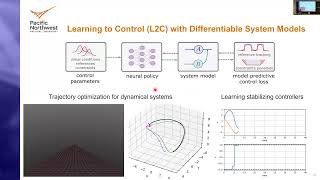
Differentiable Programming for Data-driven Modeling, Optimization, and Control
Explore data-driven modeling, optimization, and control through differentiable programming techniques in this symposium talk by Jan Drgona from Pacific Northwest National Laboratory.
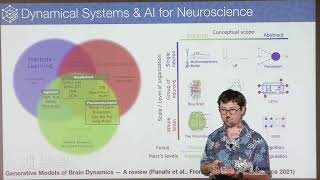
Emerging Interactions in Humans and Machines: From Social Physiology to Social Neuro-AI
Explore social cognition through multi-brain neuroscience and neuro-inspired AI, bridging intra-personal mechanisms and inter-personal dynamics to understand higher-level intelligence in humans and machines.
Properties of Chaotic Systems for Audio
Explore chaotic systems for audio generation and transformation. Learn about fixed points, bifurcation, and practical applications with interactive visualizations and code examples.
Phase and Frequency Synchronization of Nonlocally Coupled Oscillators
Explore phase and frequency synchronization in nonlocally coupled oscillators, delving into complex network dynamics and their applications.
Nonholonomic Systems with Inequality Constraints
Explore nonholonomic systems with inequality constraints, delving into advanced concepts and applications in control theory and robotics.
Expressiveness and Structure Preservation in Learning Port Hamiltonian Systems
Explore advanced techniques for learning Port Hamiltonian systems, focusing on expressiveness and structure preservation in dynamic modeling and control applications.
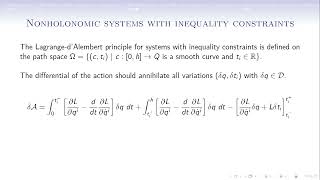
Nonholonomic Systems with Inequality Constraints
Explore nonholonomic systems with inequality constraints, delving into advanced concepts and applications in control theory and robotics.
Hierarchical Perspective on Robotic Control
Explore hierarchical control strategies for complex robotic systems, focusing on dynamically stable behaviors in 3D hopping and planar bipedal robots. Learn about geometric and nonlinear control in hierarchical architectures.
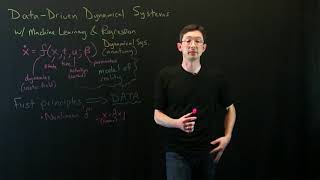
Data-Driven Dynamical Systems Overview
Overview of data-driven approaches to tackle challenges in modern dynamical systems, exploring machine learning techniques for nonlinear and unknown dynamics, prediction, and control.
Detecting Bifurcations in Dynamical Systems with Zigzag Persistent Homology
Explore zigzag persistent homology for efficient detection of bifurcations in dynamical systems, reducing computational costs and capturing topological changes in a single persistence diagram.
Nonlinear Dynamics, High Dimensional Data, and Persistent Homology
Explore nonlinear dynamics, high-dimensional data analysis, and persistent homology with Konstantin Mischaikow. Learn about algebraic topology applications, persistence diagrams, and recent advancements in data science.