Women's Research Day 2021 - Welcome and Keynote
Celebration of women and nonbinary researchers in computer science, featuring a welcome address and keynote presentation on innovative research and the vision behind Women's Research Day.
Policy Learning in Spatial Action Spaces for Robotic Manipulation
Explore innovative approaches to robotic policy learning in spatial action spaces for complex manipulation tasks, addressing challenges and evaluating solutions in simulated and physical environments.
Scaling Probabilistically Safe Learning to Robotics
Explores advancements in safe robot learning, focusing on imitation learning theory, scalable reward inference, and efficient policy evaluation to enable real-world deployment with safety guarantees.
Formal Synthesis for Robots - Leveraging Formal Methods in Robotic Design
Explore how formal methods and synthesis techniques can design, explain, and guarantee robot behavior, with examples of modular robots, swarms, and human-robot interaction.
Robot Learning From Few Demonstrations by Exploiting Data Structure and Geometry
Explore robot learning from limited demonstrations, leveraging data structure and geometry. Discover optimal control strategies and intuitive interfaces for efficient skill acquisition in human-robot interaction.
Hierarchy, Abstractions and Geometry in Robotics - Spring 2021 Robotics Colloquium
Explore advanced robotics concepts, focusing on abstract reasoning and joint semantic-physical representations for improved planning and decision-making in complex environments.
Structuring Manipulation Tasks for More Efficient Learning
Exploring modular approaches to teach robots versatile manipulation skills for unstructured environments, focusing on object-centric solutions, context adaptation, and material-based interactions.
Feedback Design Principles for Efficient and Reliable Robot Learning
Exploring fusion of feedback control and reinforcement learning for efficient, reliable robot learning. Discusses reward shaping, co-design of controllers and algorithms, and future directions in robotics.
Next-Generation Robot Perception: Hierarchical Representations, Certifiable Algorithms, and Self-Supervised Learning
Exploring next-gen robot perception: hierarchical representations, certifiable algorithms, and self-supervised learning for enhanced spatial understanding and robust estimation in robotics.
Stability and Learning in Strategic Queueing Systems
Explore stability and learning in strategic queueing systems with Éva Tardos. Discover how selfish behavior affects packet routing and server capacity in this insightful seminar on optimization and data analysis.
Towards $1 Robots
Explore the future of accessible robotics through innovative design, fabrication, and control methods. Learn how low-cost robots can revolutionize work, education, and play for everyone worldwide.
Interactive Imitation Learning - Planning Alongside Humans
Explore interactive imitation learning for robots to adapt to human preferences, focusing on challenges beyond dataset collection and enabling seamless human-robot collaboration in real-world scenarios.
Building Trusted Systems on Top of Leaky Abstractions
Exploring secure system design in complex tech stacks. Covers side-channel attacks, browser security, and trusted execution environments. Insights on building robust systems against known and unknown threats.
Linear Quadratic Control and Online Learning - 2019 ADSI Summer Workshop
Explore linear quadratic control and online learning with Yishay Mansour. Gain insights into algorithmic foundations of learning and control in this comprehensive workshop presentation.
An Online Learning Approach to Model Predictive Control - 2019 ADSI Summer Workshop
Explore online learning approaches to Model Predictive Control with Byron Boots, focusing on algorithmic foundations and innovative applications in learning and control systems.
Convex Optimization I - Fundamentals and Applications
Explore fundamental concepts and applications of convex optimization with Microsoft researcher Sebastien Bubeck in this comprehensive lecture on mathematical programming techniques.

Distributed Systems: Consensus and Replication - Lecture 10
Explore advanced topics in distributed systems, focusing on consensus algorithms, fault tolerance, and scalability in large-scale networks.

Distributed Systems: Synchronization and Coordination - Lecture 2
Explore advanced distributed systems concepts, focusing on consensus algorithms, fault tolerance, and scalability in large-scale networked environments.
Measuring Sleep, Stress and Wellbeing with Wearable Sensors and Mobile Phones
Exploring wearable sensors and mobile phones to measure and improve sleep, stress, and mental wellbeing through data analysis, machine learning, and personalized interventions.
Social Cybersecurity: Reshaping Security Through Human Social Behavior
Exploring social factors in cybersecurity: empirical analyses of security tool adoption and the development of Thumprint, a socially intelligent authentication system for small groups.
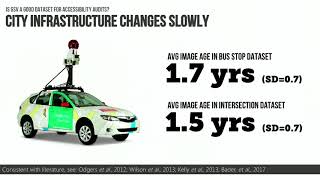
Making with a Social Purpose - Interactive Tools for Global Challenges
Interactive tools addressing global challenges in accessibility and STEM education. Explores crowdsourcing for urban accessibility and wearable technology for children's STEM learning experiences.