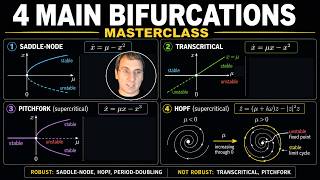
Bifurcation Theory - Saddle-Node, Hopf, Transcritical, Pitchfork
Explore saddle-node, transcritical, pitchfork, and Hopf bifurcations in dynamical systems. Learn how these phenomena affect phase portraits and system behavior as parameters change.
Friction and Phase Portraits - Coulomb Friction - Cone of Friction - Falling Broom - Spinning Top
Explore Coulomb friction, phase portraits, and 3D rigid body dynamics. Analyze friction effects on equilibrium, falling objects, and spinning tops using experiments and mathematical models.
Phase Portraits from Potential Energy - Bifurcations - Constraint Forces from Lagrange Multipliers
Explore phase portraits, bifurcations, and constraint forces in dynamical systems. Learn graphical methods, analyze system behavior changes, and understand Lagrangian mechanics with practical applications.
Lagrange’s Equations with Conservative and Non-Conservative Forces - Phase Space Introduction
Explore Lagrange's equations for conservative and non-conservative forces, rigid body systems, and phase space analysis. Learn to solve and classify motions using advanced analytical dynamics techniques.
Drawing Phase Portraits for Nonlinear Systems
Learn to analyze nonlinear systems by drawing phase portraits, identifying fixed points, linearizing, and inferring global dynamics. Gain practical skills in stability analysis using eigenvalues and eigenvectors.
Systems of ODEs: Imaginary Eigenvalues and Center Fixed Points
Explore imaginary eigenvalues and center fixed points in 2D ODE systems. Learn to compute eigenvectors, write solutions, and understand geometric intuition behind rotational dynamics.
Systems of ODEs - Saddle Points and Instability
Explore unstable saddle points in 2D linear ODEs, their applications in energy-efficient transport, and analysis using eigenvalues, eigenvectors, and phase portraits.

Examples of Nonlinear Systems - Particle in a Potential Well
Explore nonlinear systems through the particle in a potential well example, covering Euler-Lagrange equations, vector fields, phase portraits, and damping in engineering mathematics.
2x2 Systems of ODEs - With Eigenvalues and Eigenvectors, Phase Portraits
Explore 2x2 systems of ODEs, eigenvalues, eigenvectors, and phase portraits in engineering mathematics. Learn to analyze and visualize complex dynamical systems.
Linearization of Nonlinear ODEs, 2x2 Systems, Phase Portraits
Explore linearization techniques for nonlinear ODEs, analyze 2x2 systems, and visualize phase portraits in this advanced engineering mathematics lecture.

Differential Equations: The Language of Change
Explore dynamical systems and differential equations through intuitive examples. Learn key concepts like state variables, phase portraits, and limit cycles to understand how systems change over time.